Ben Snell

G53, UR5

dimensions variable
paper, ink
2018

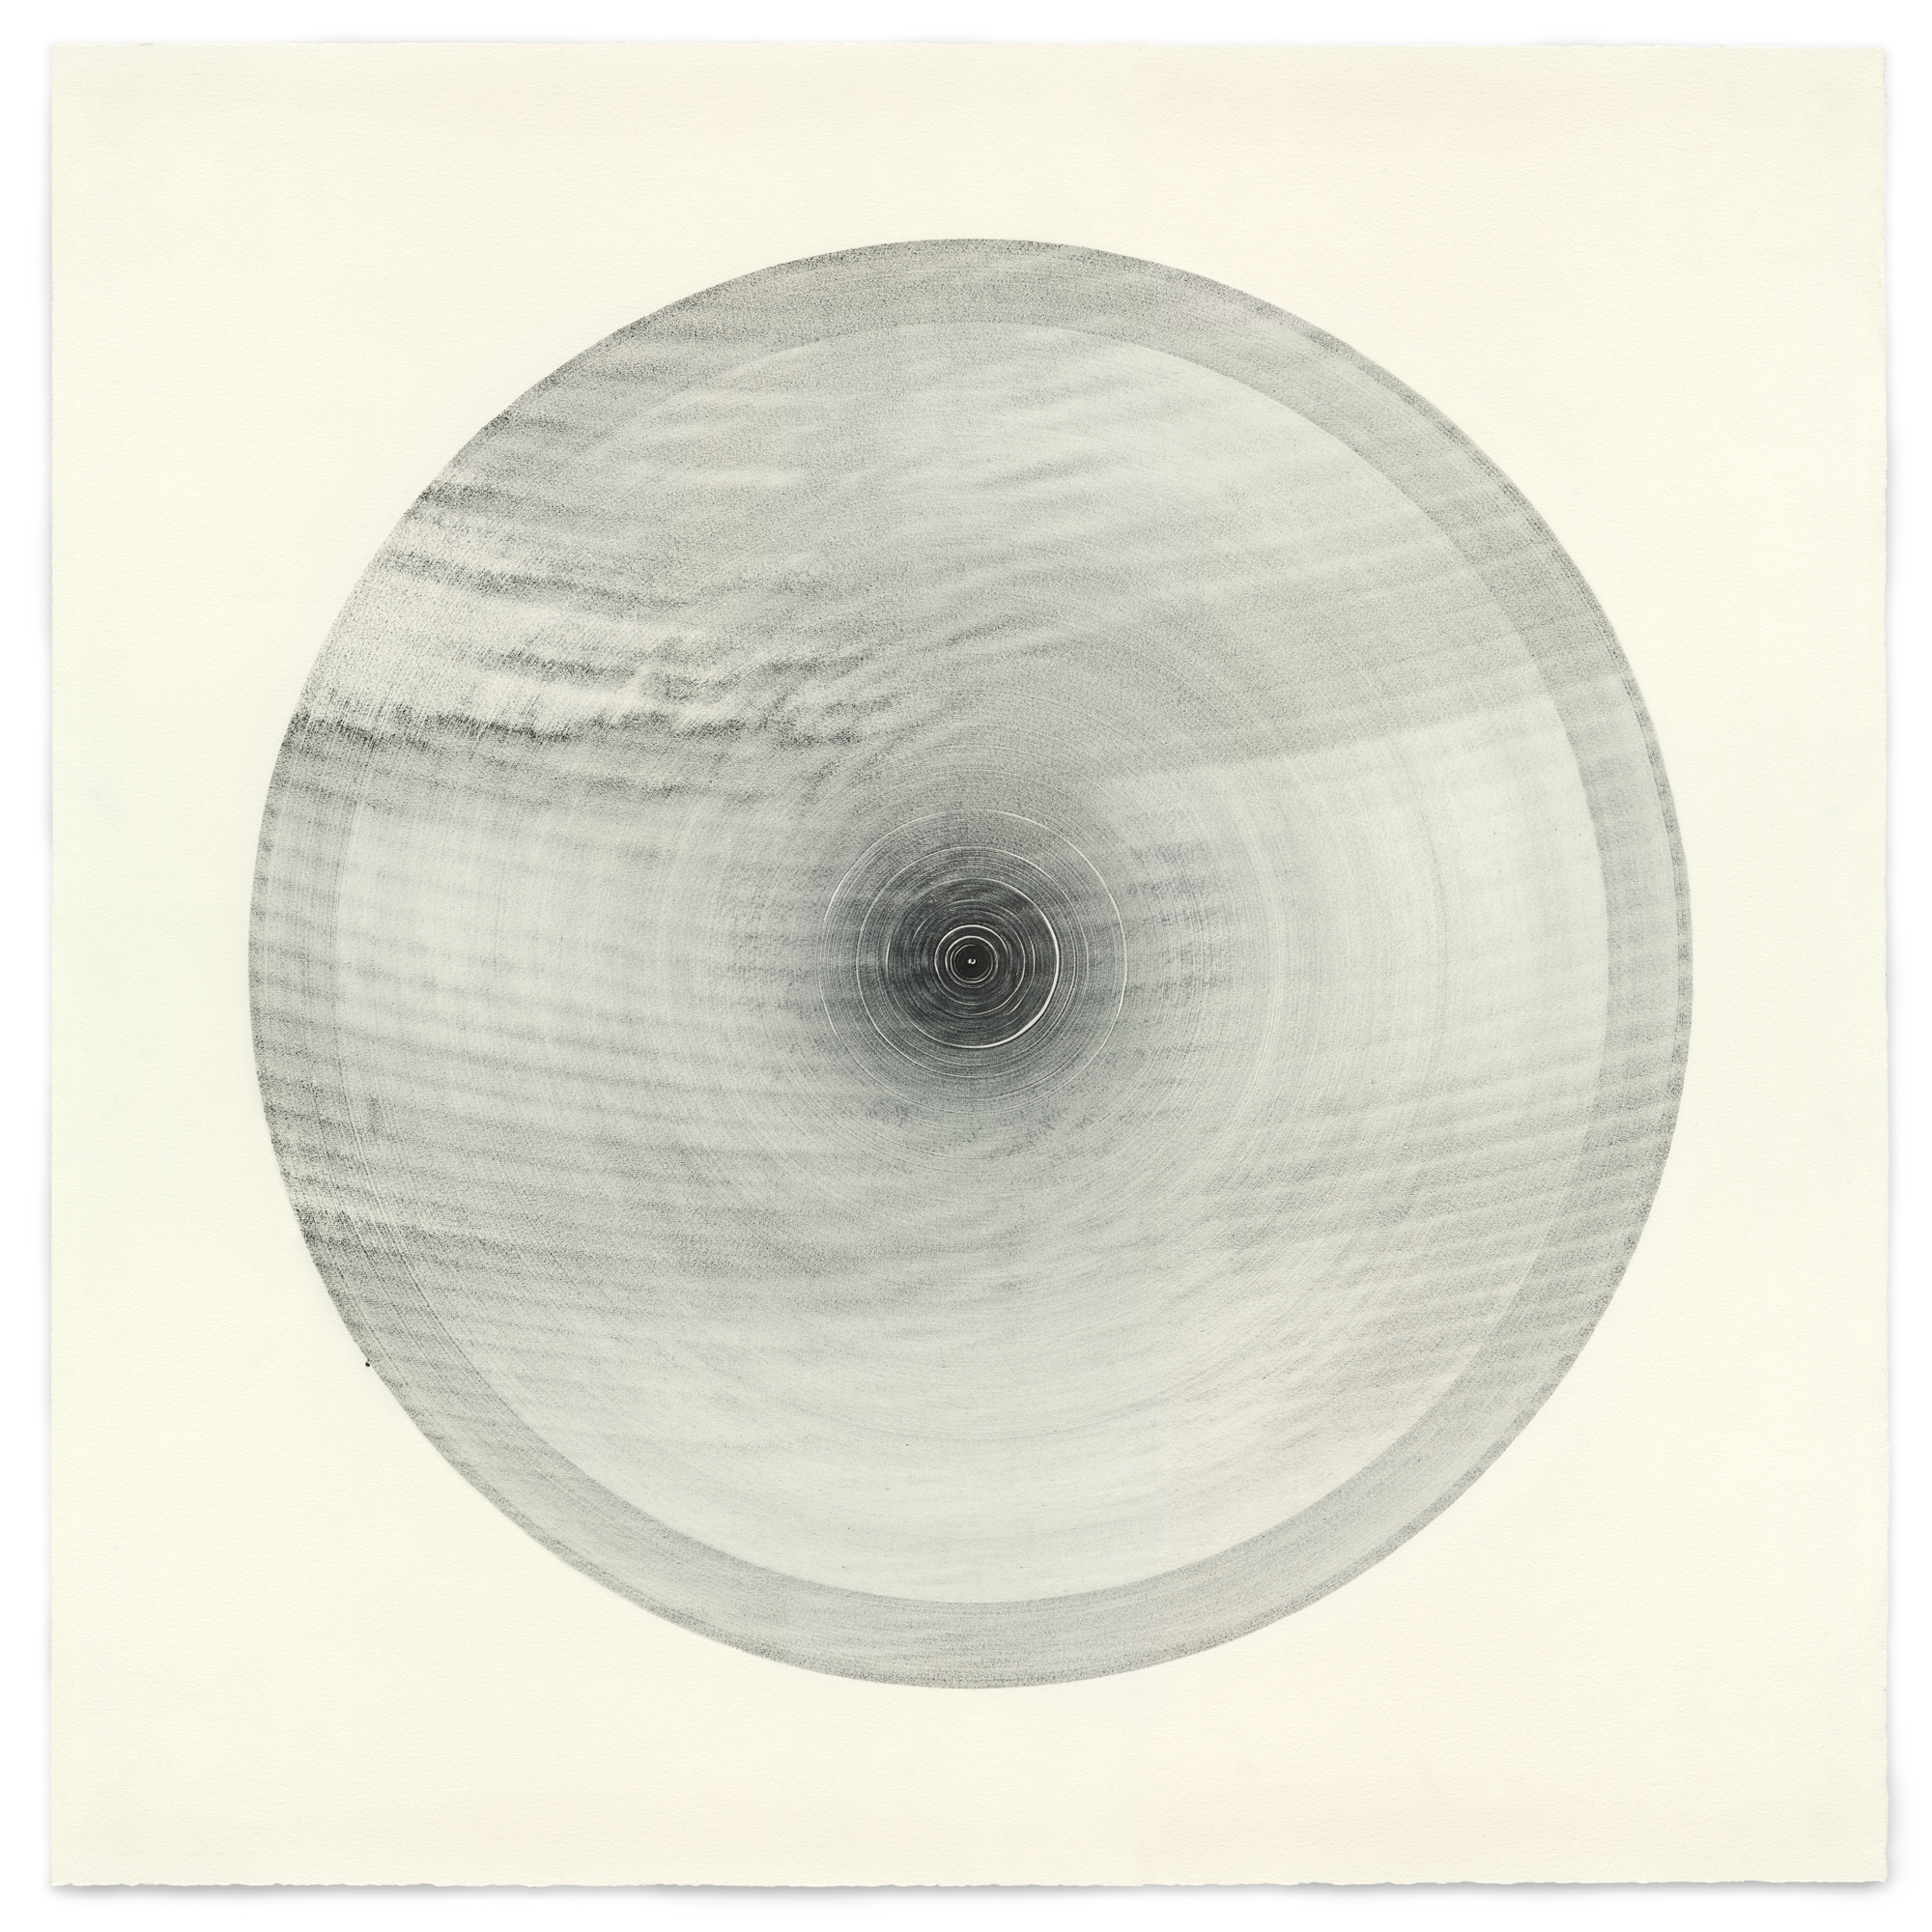
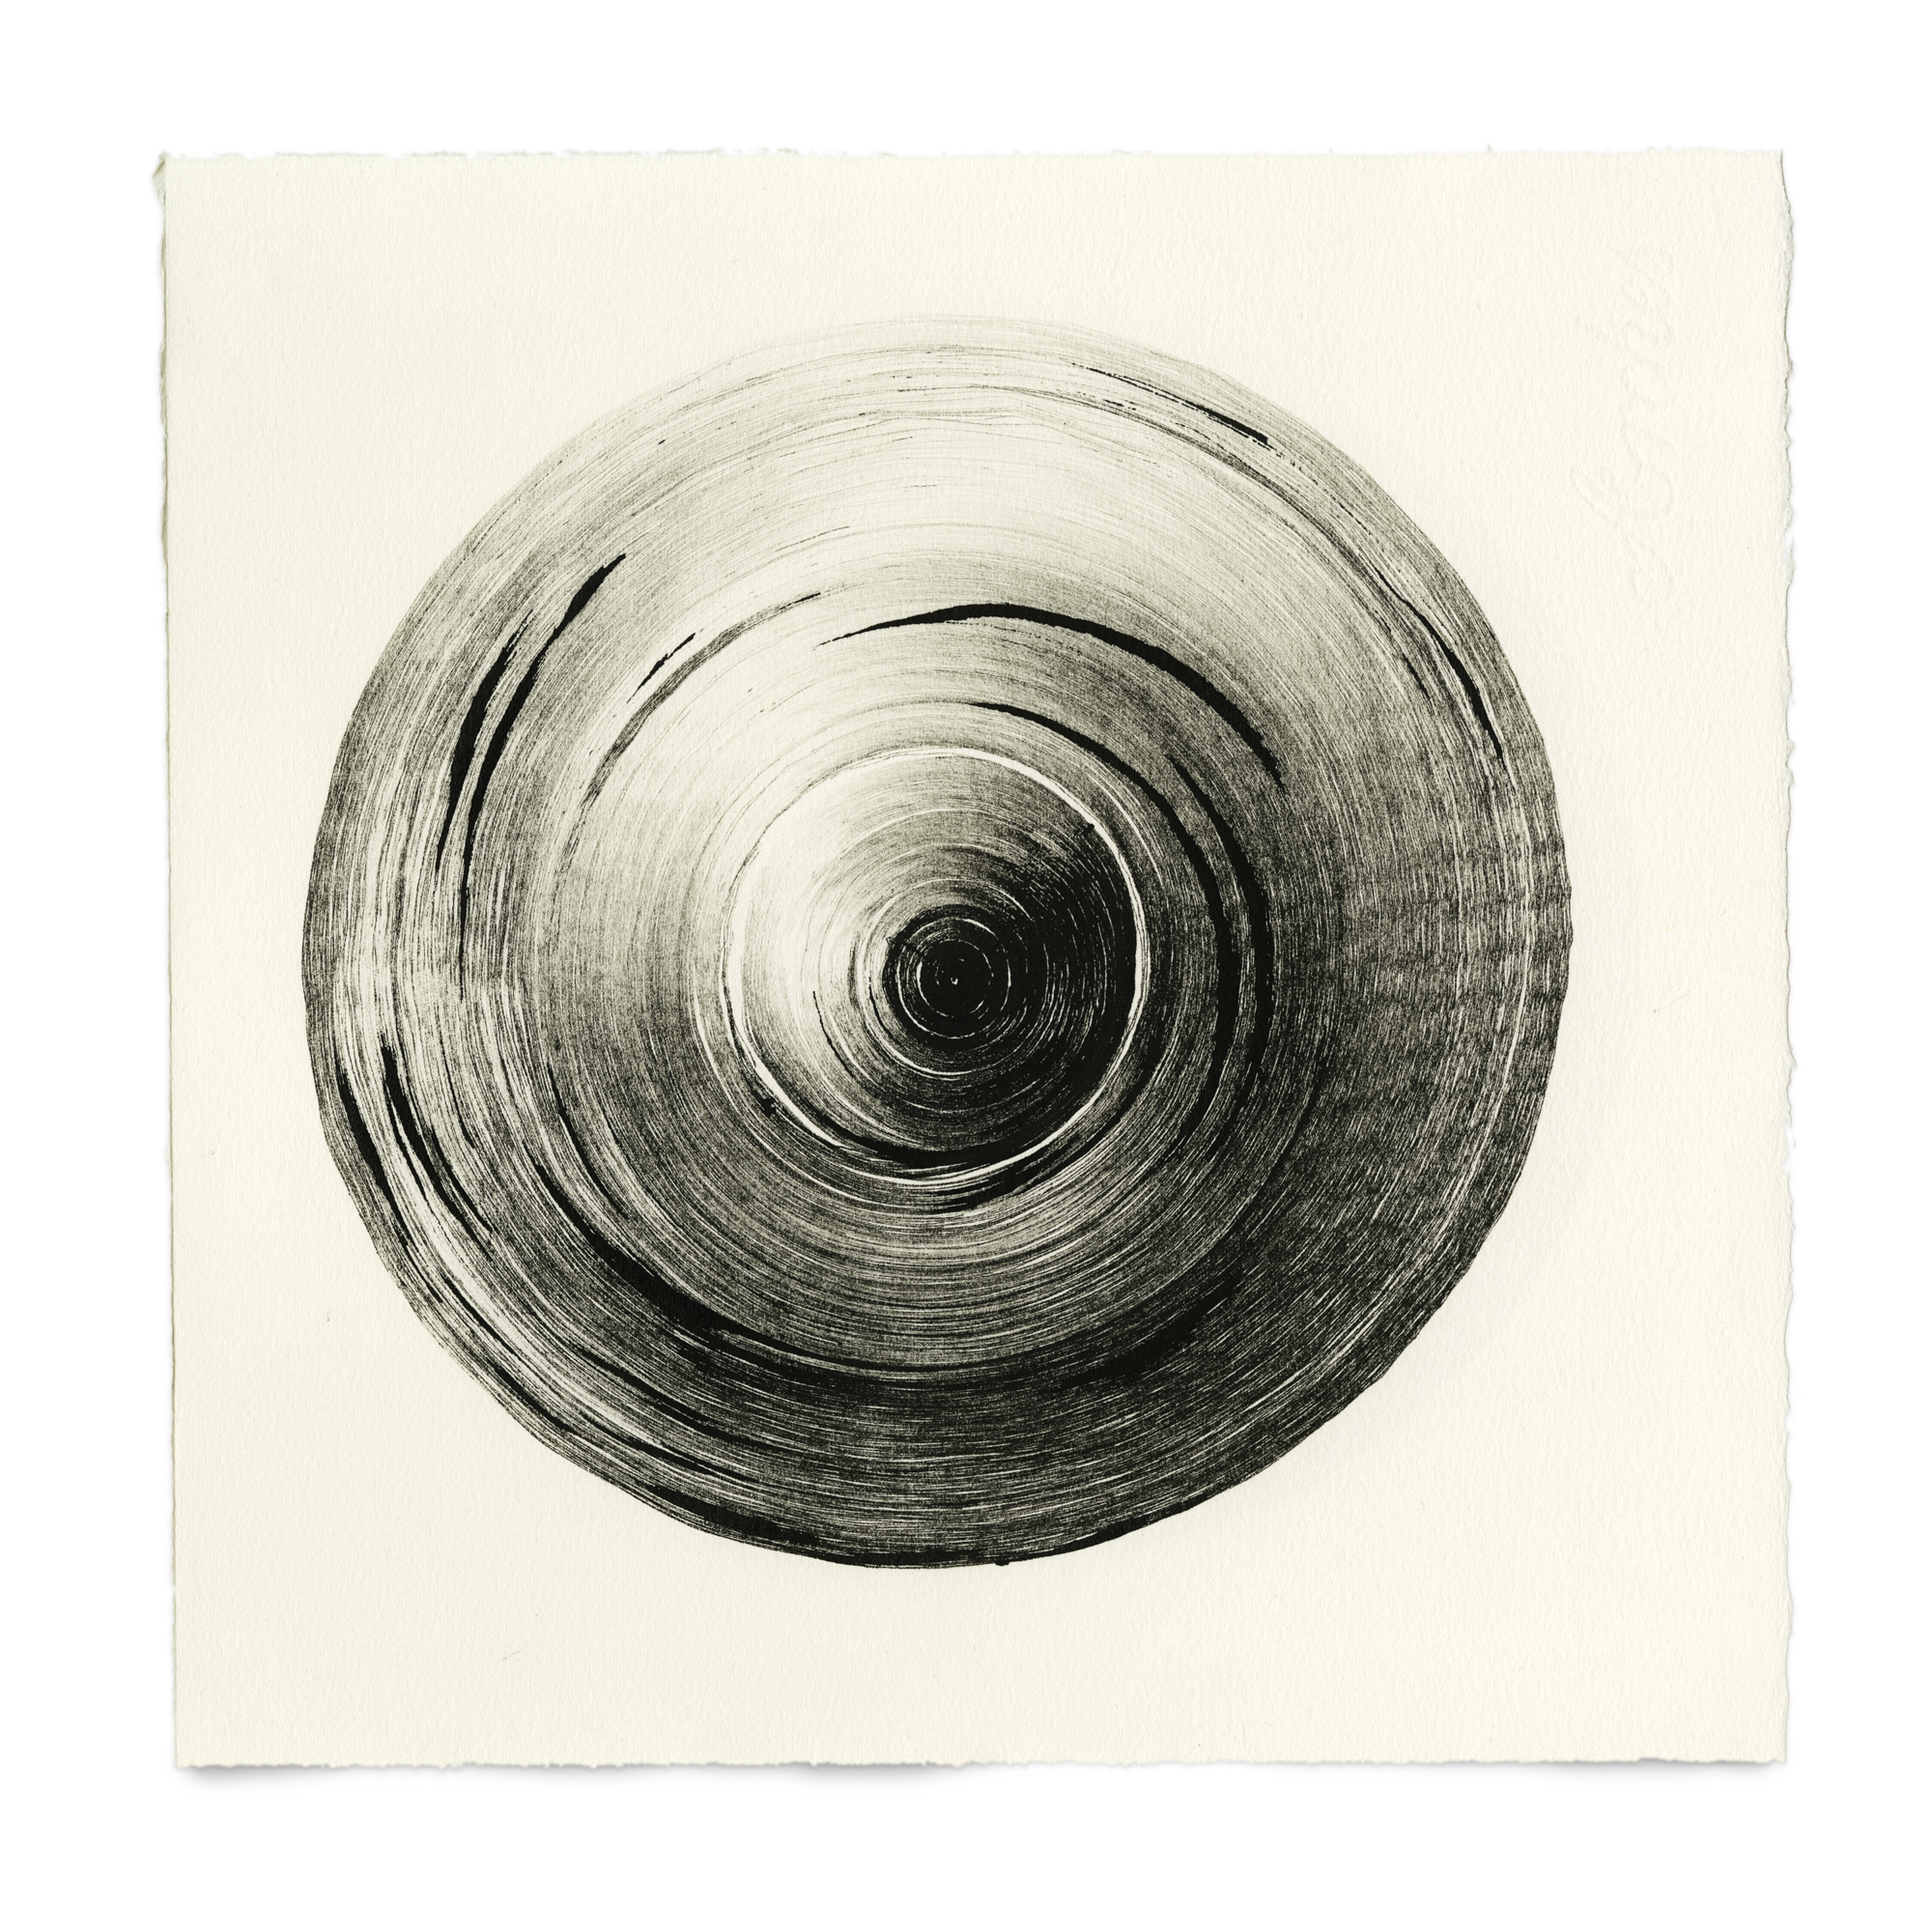
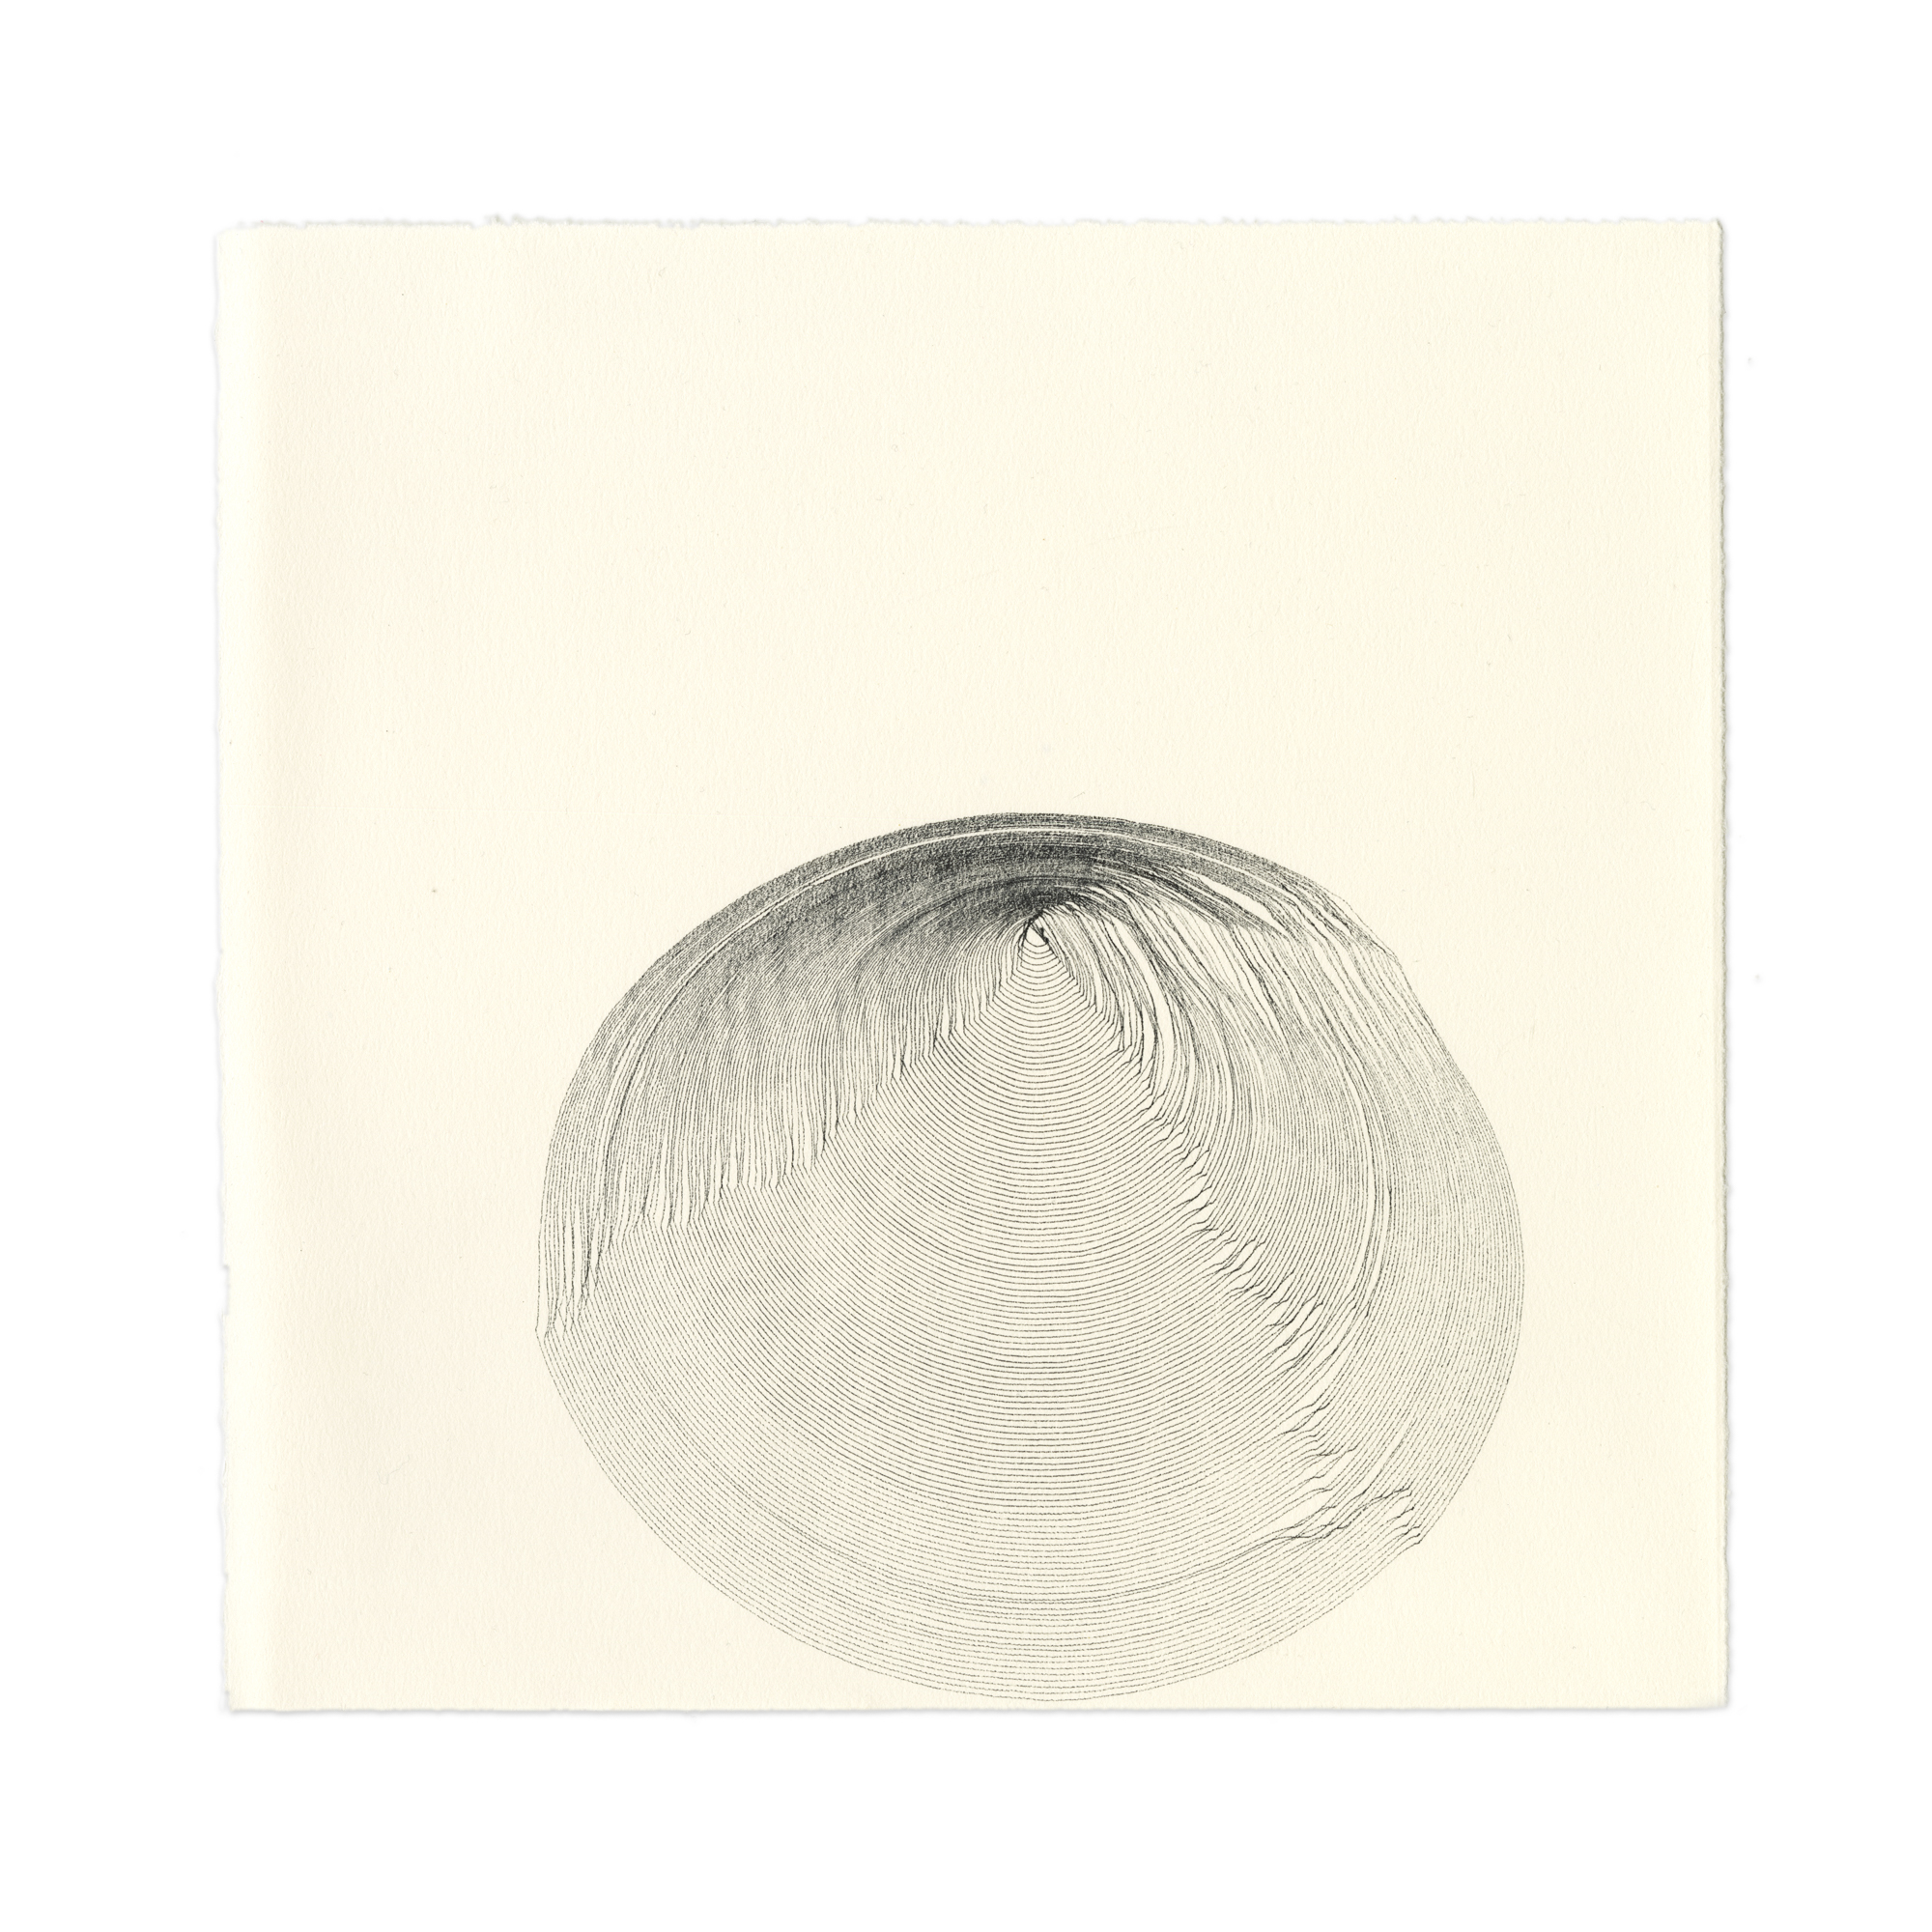
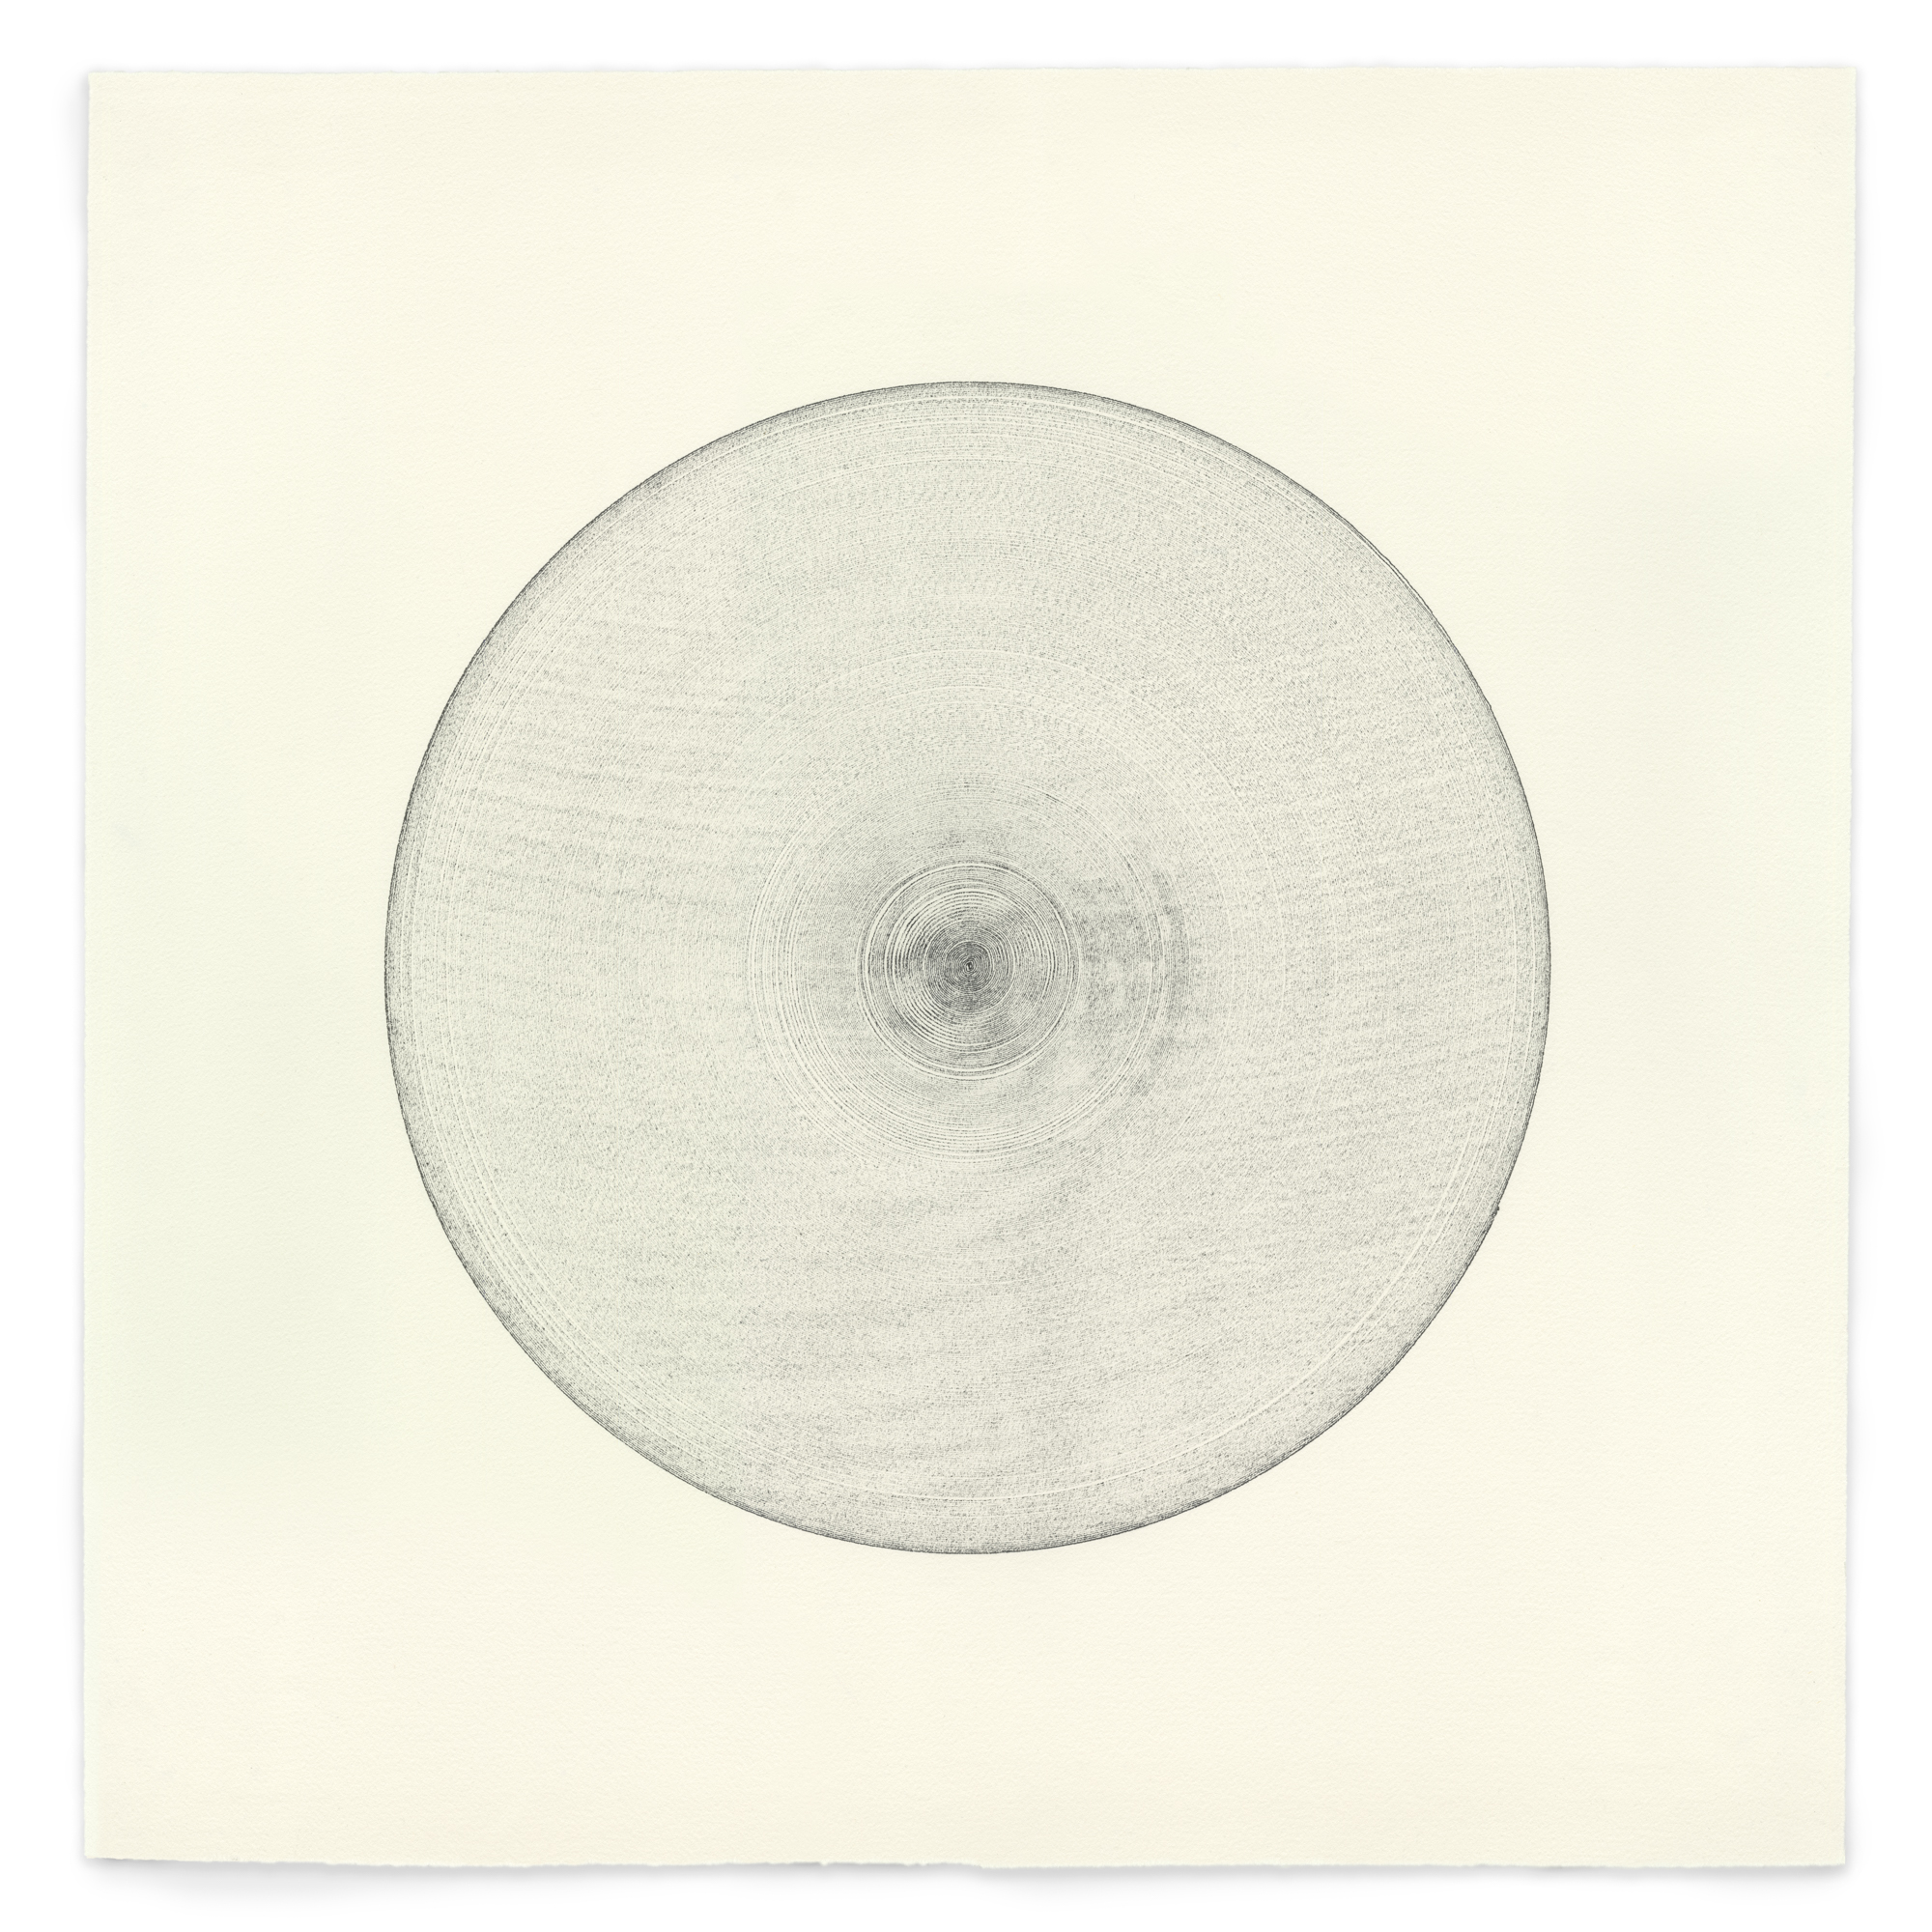
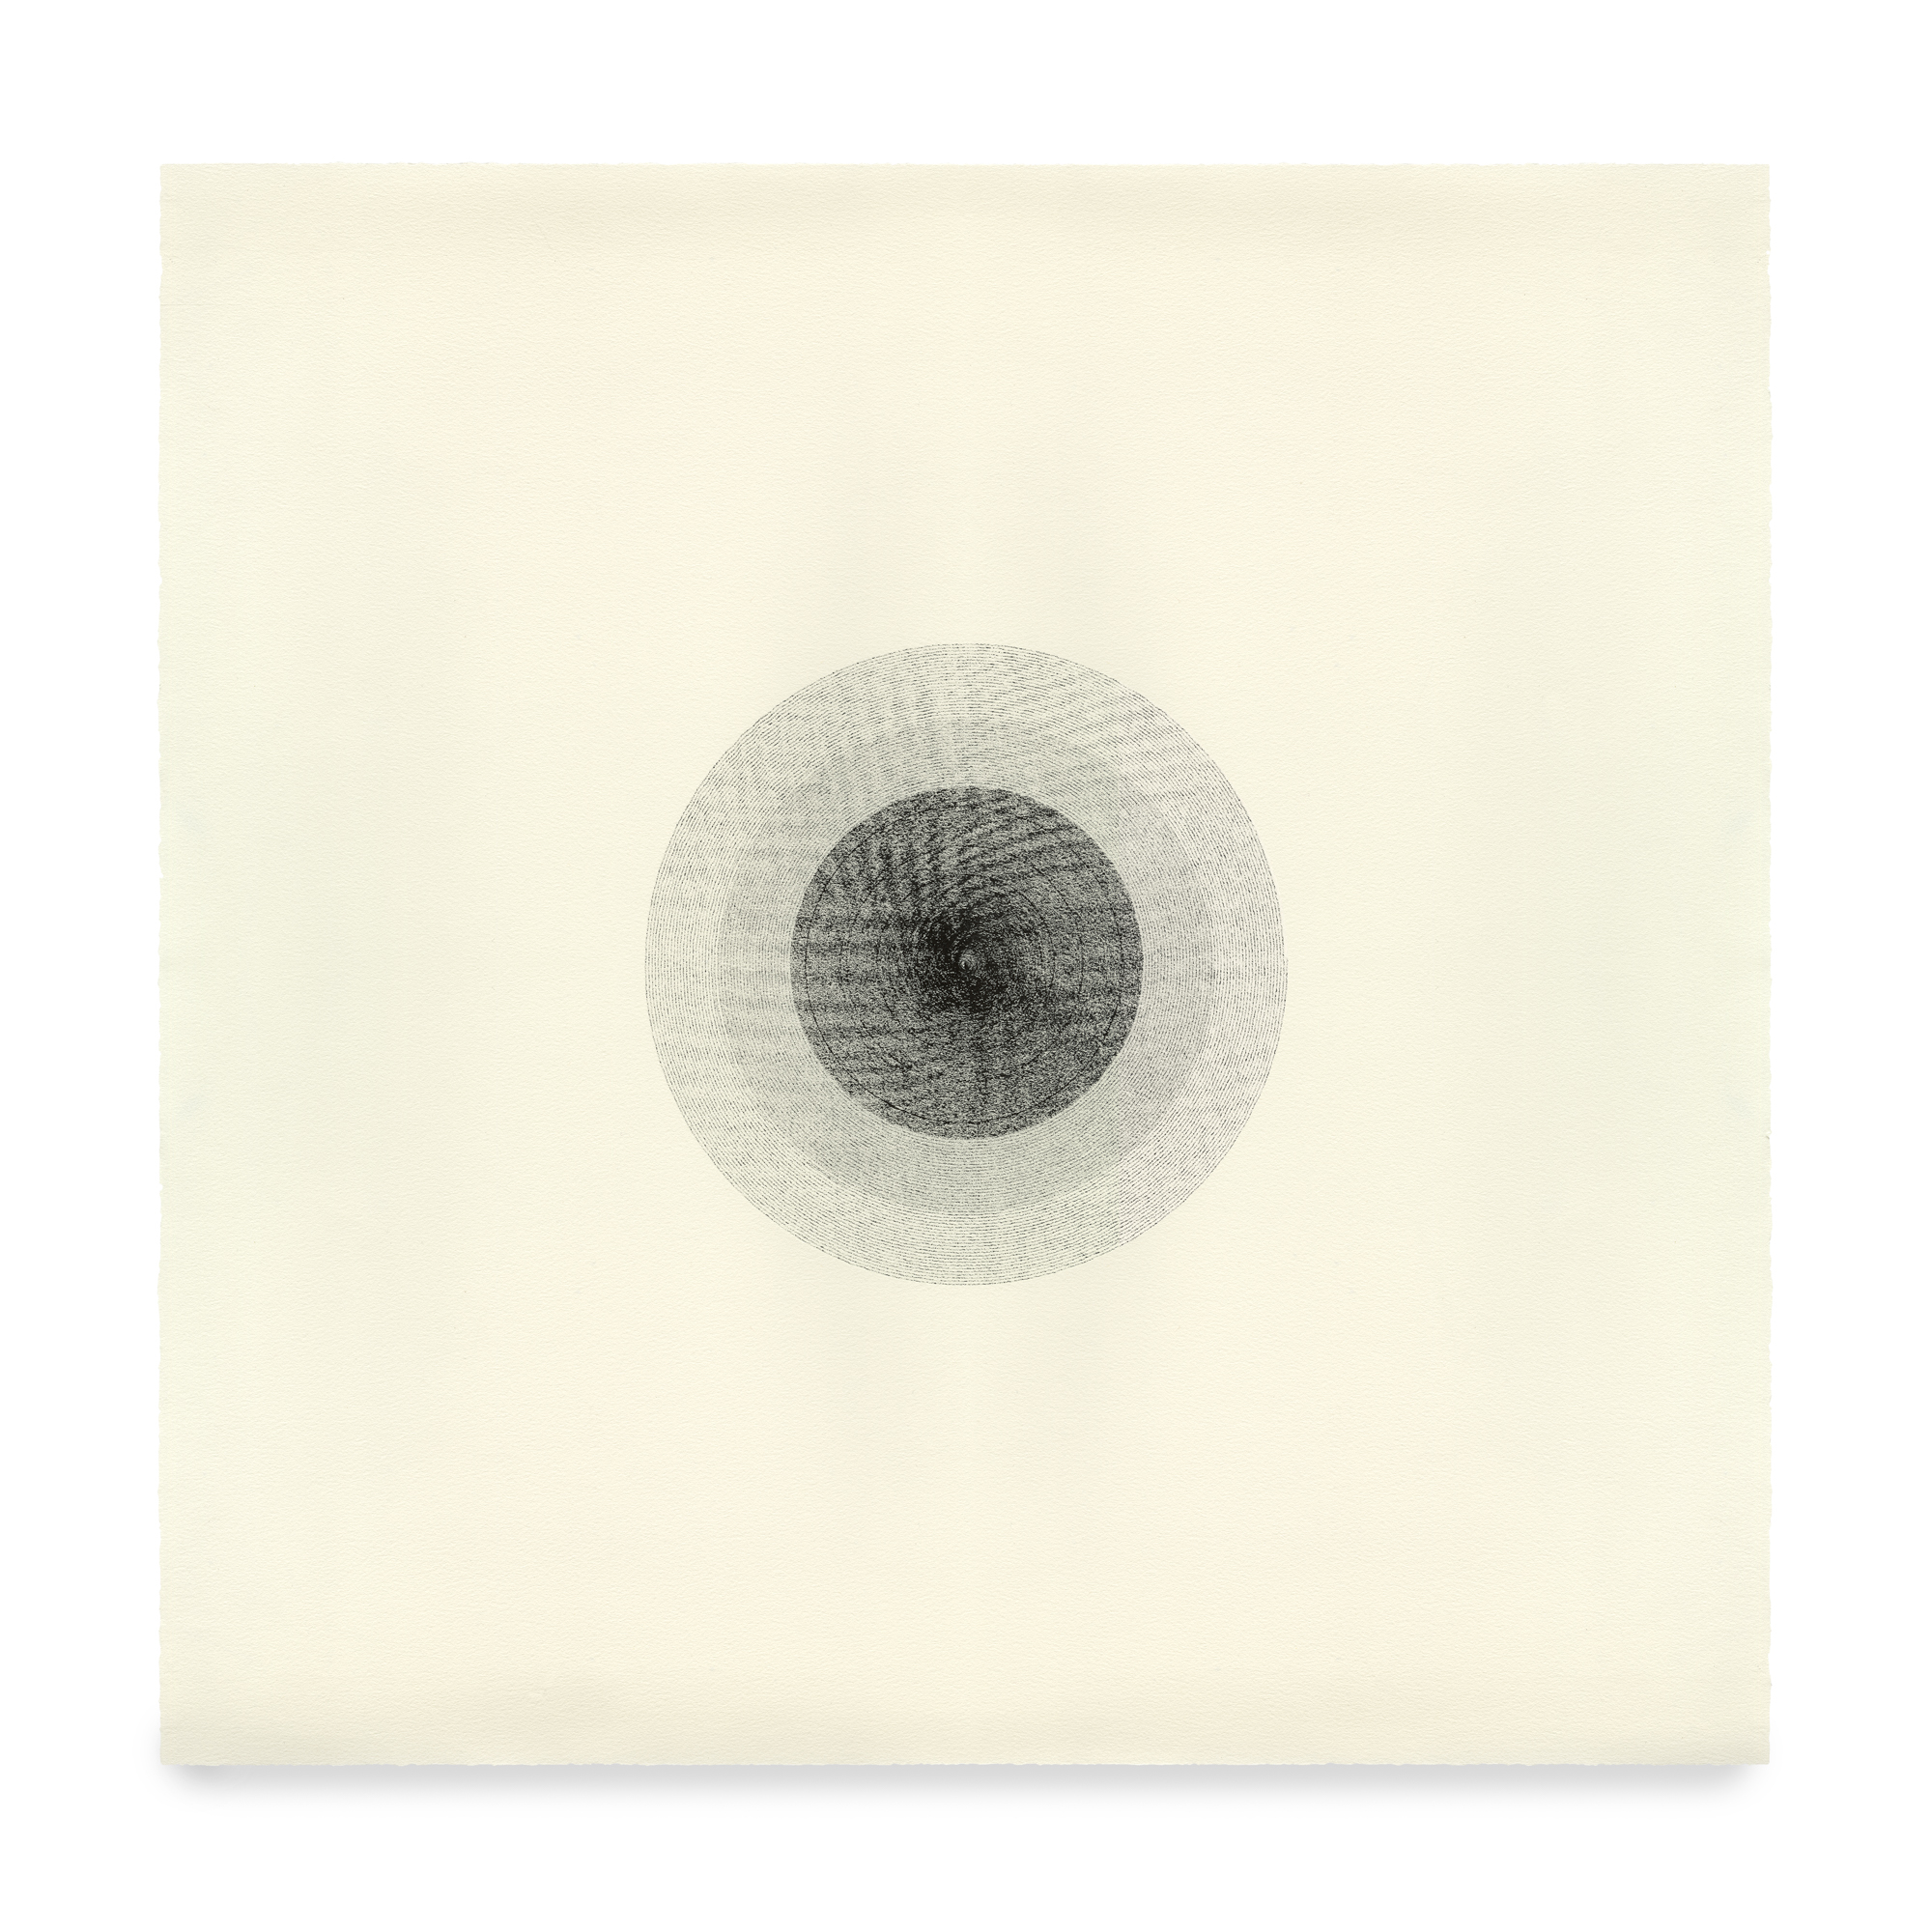
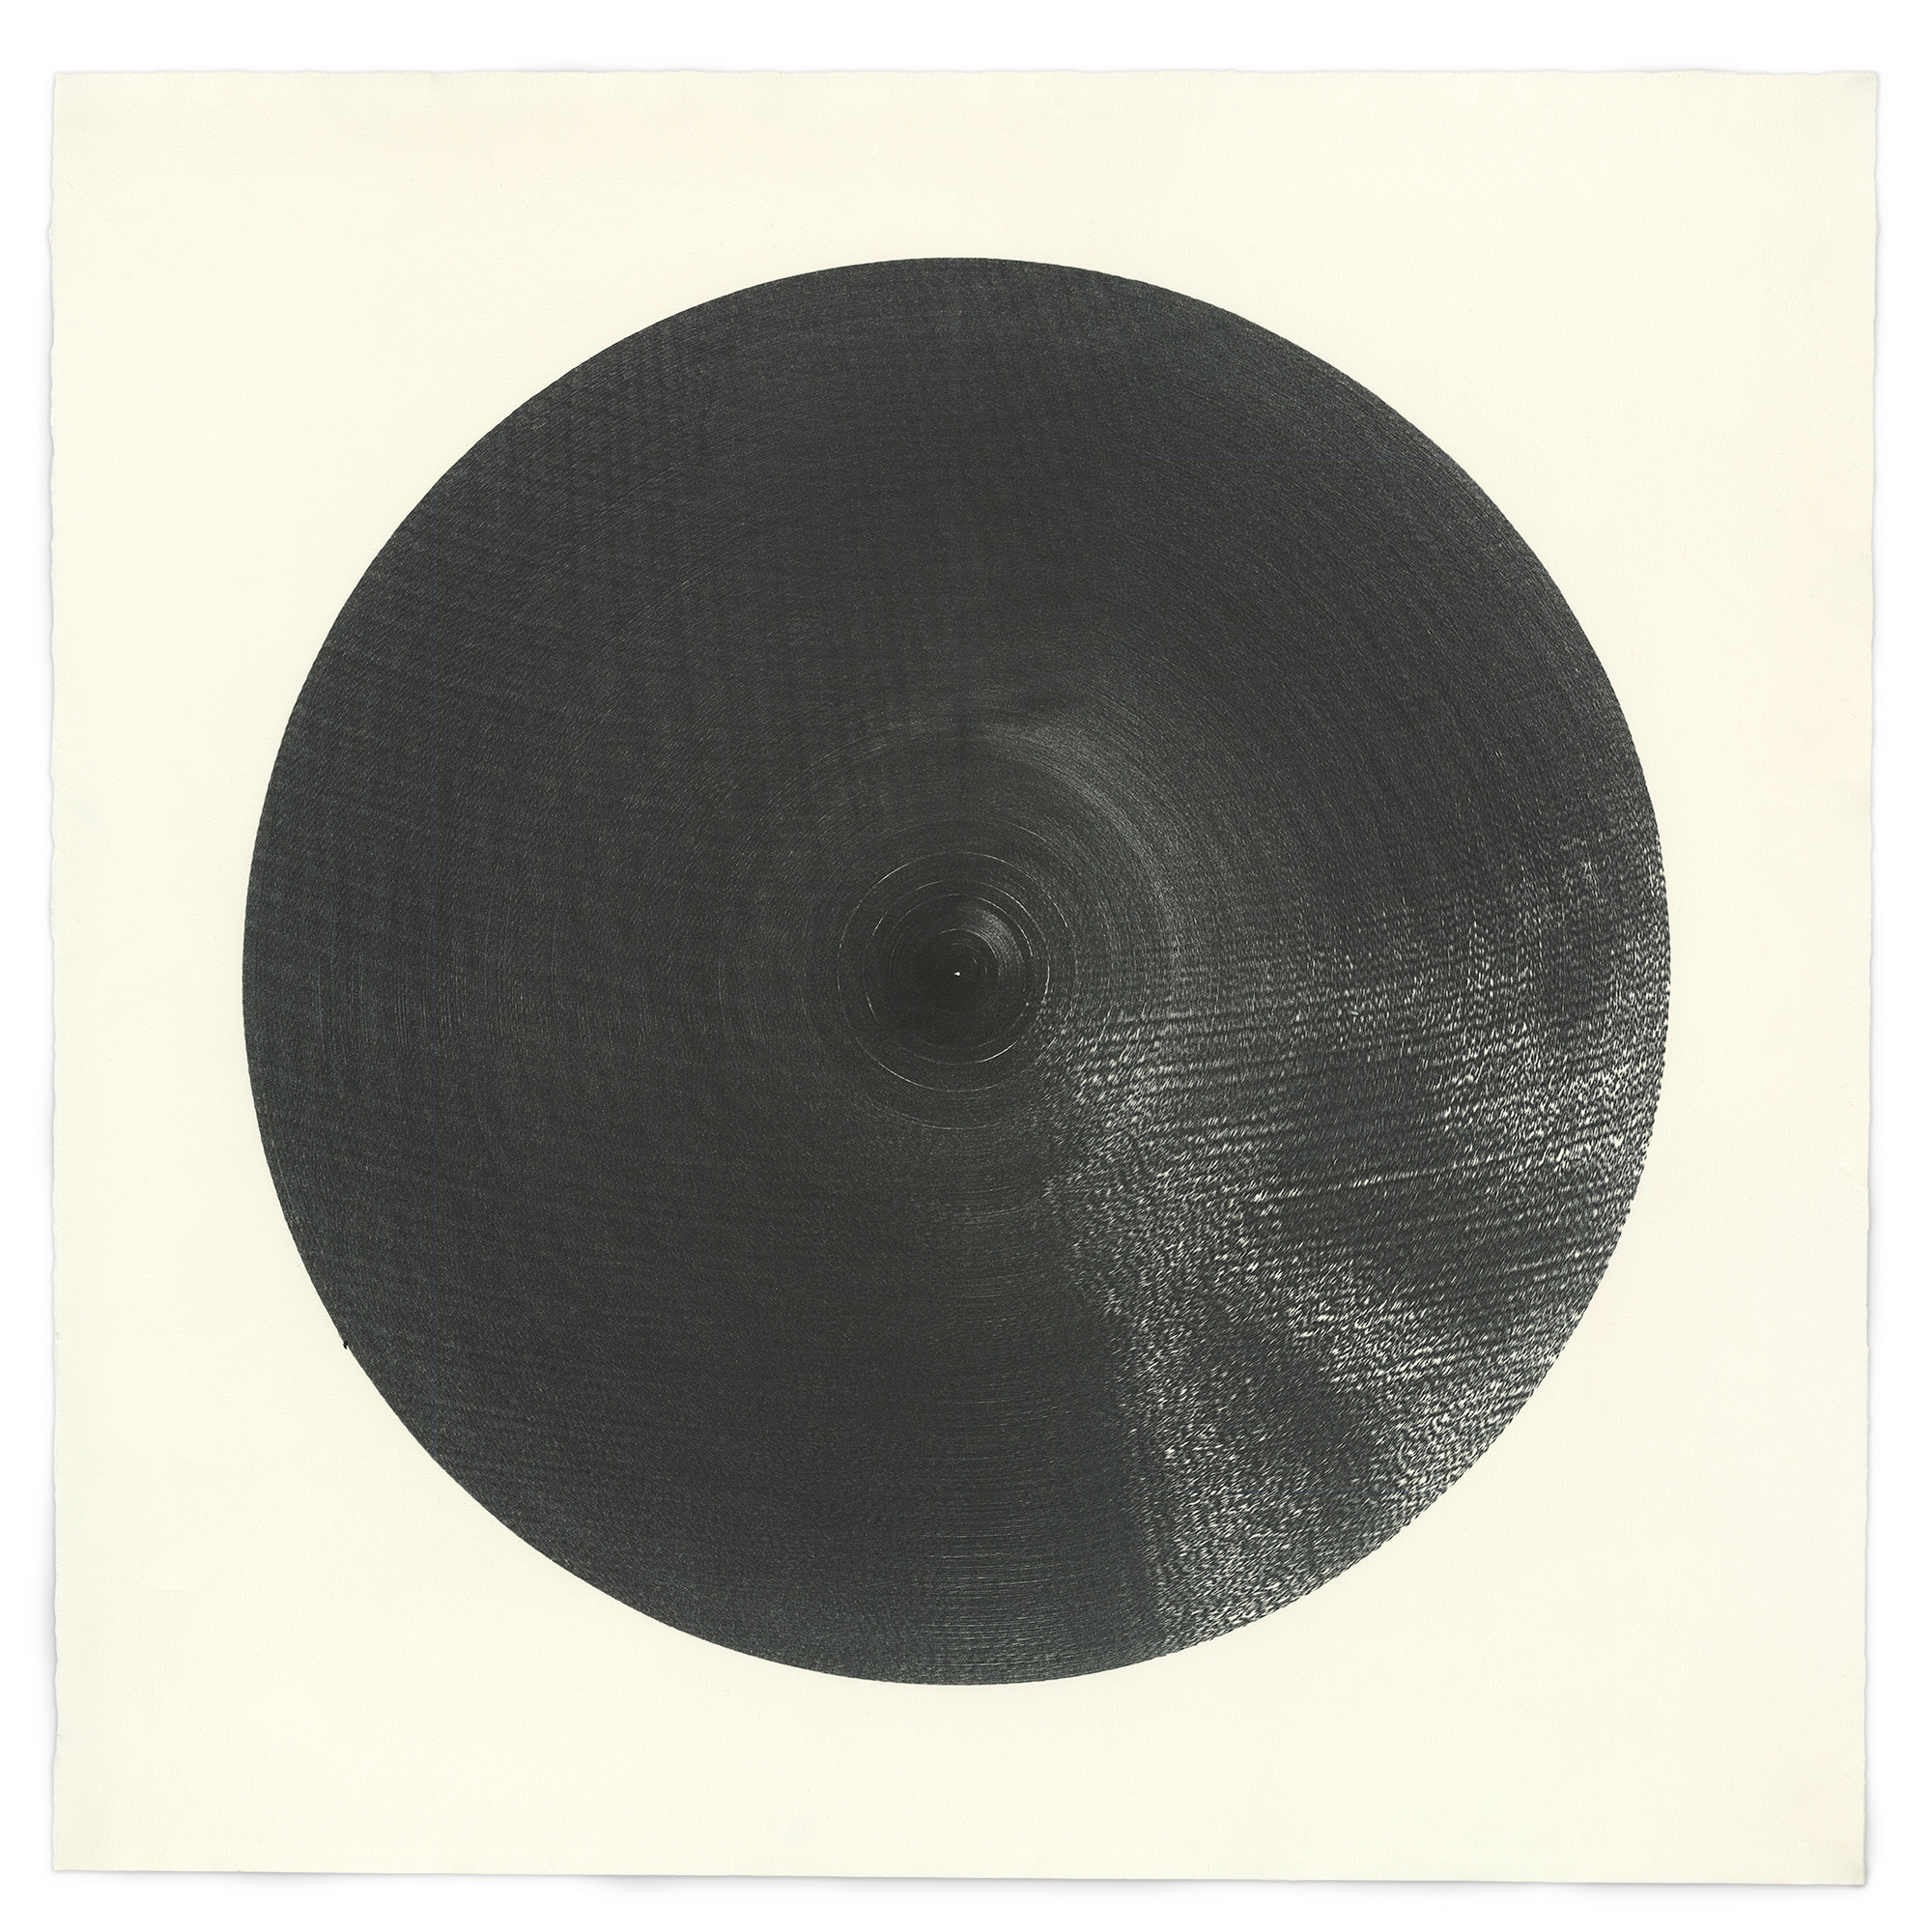
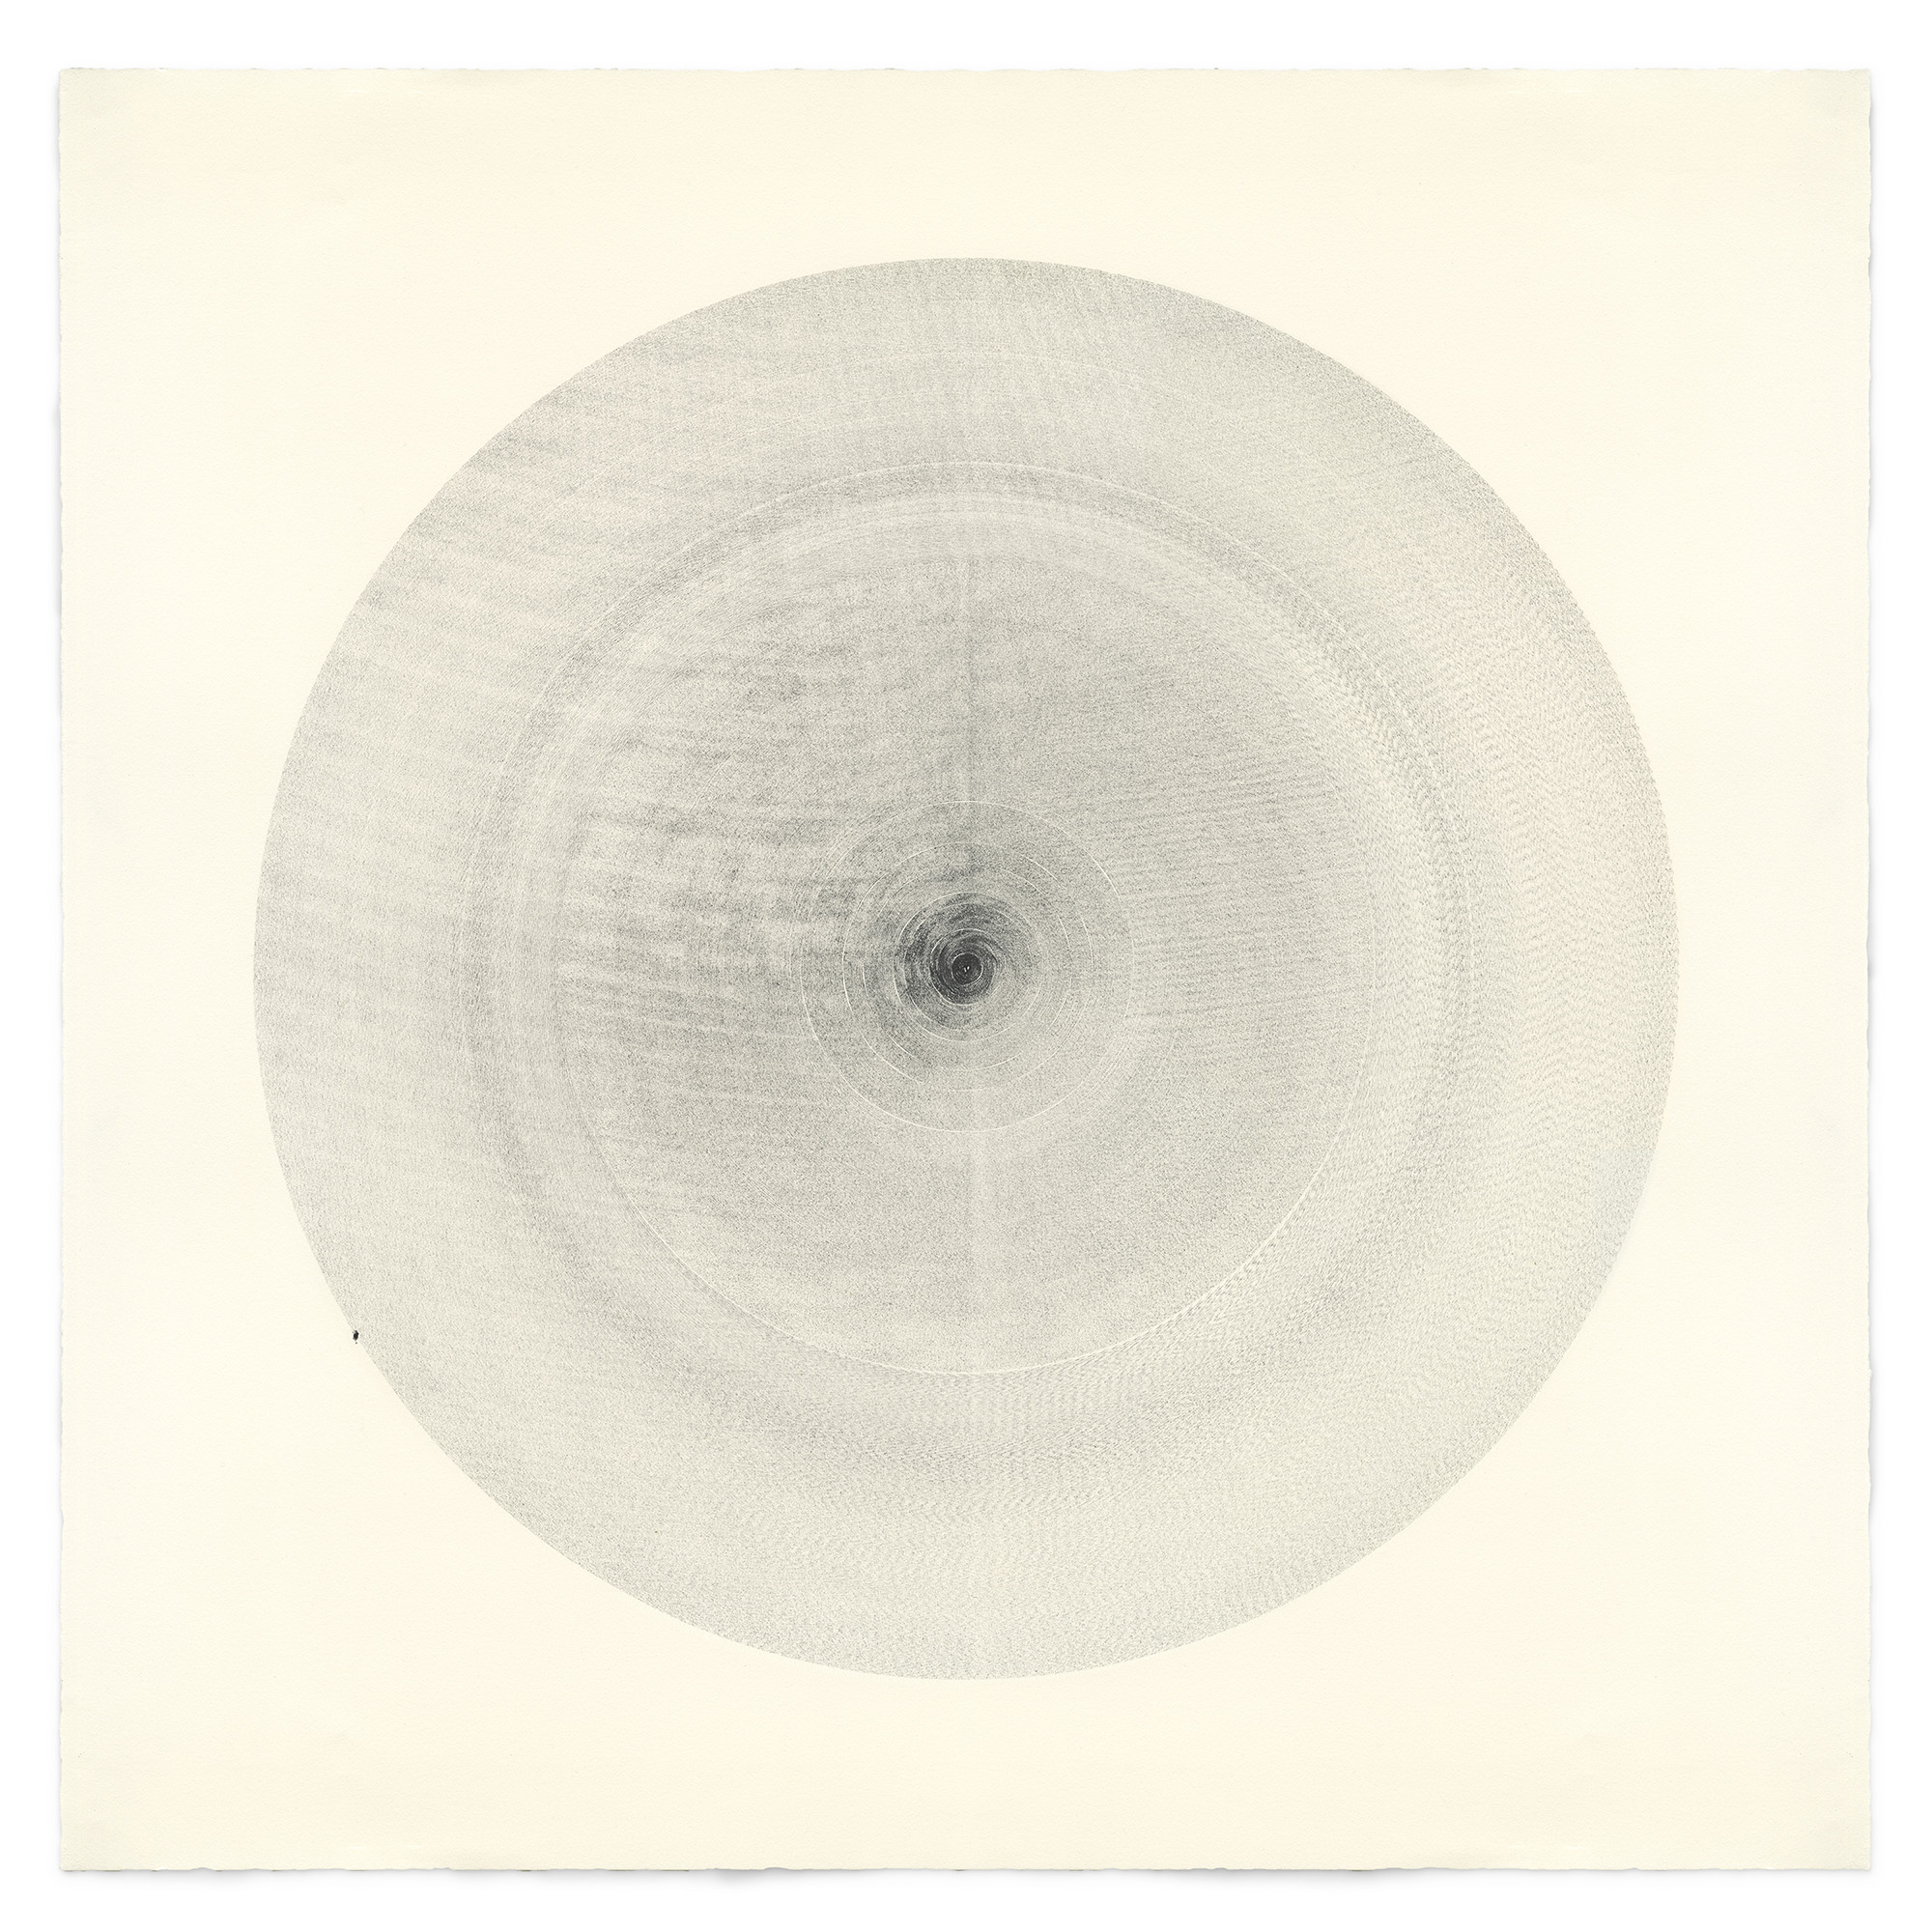
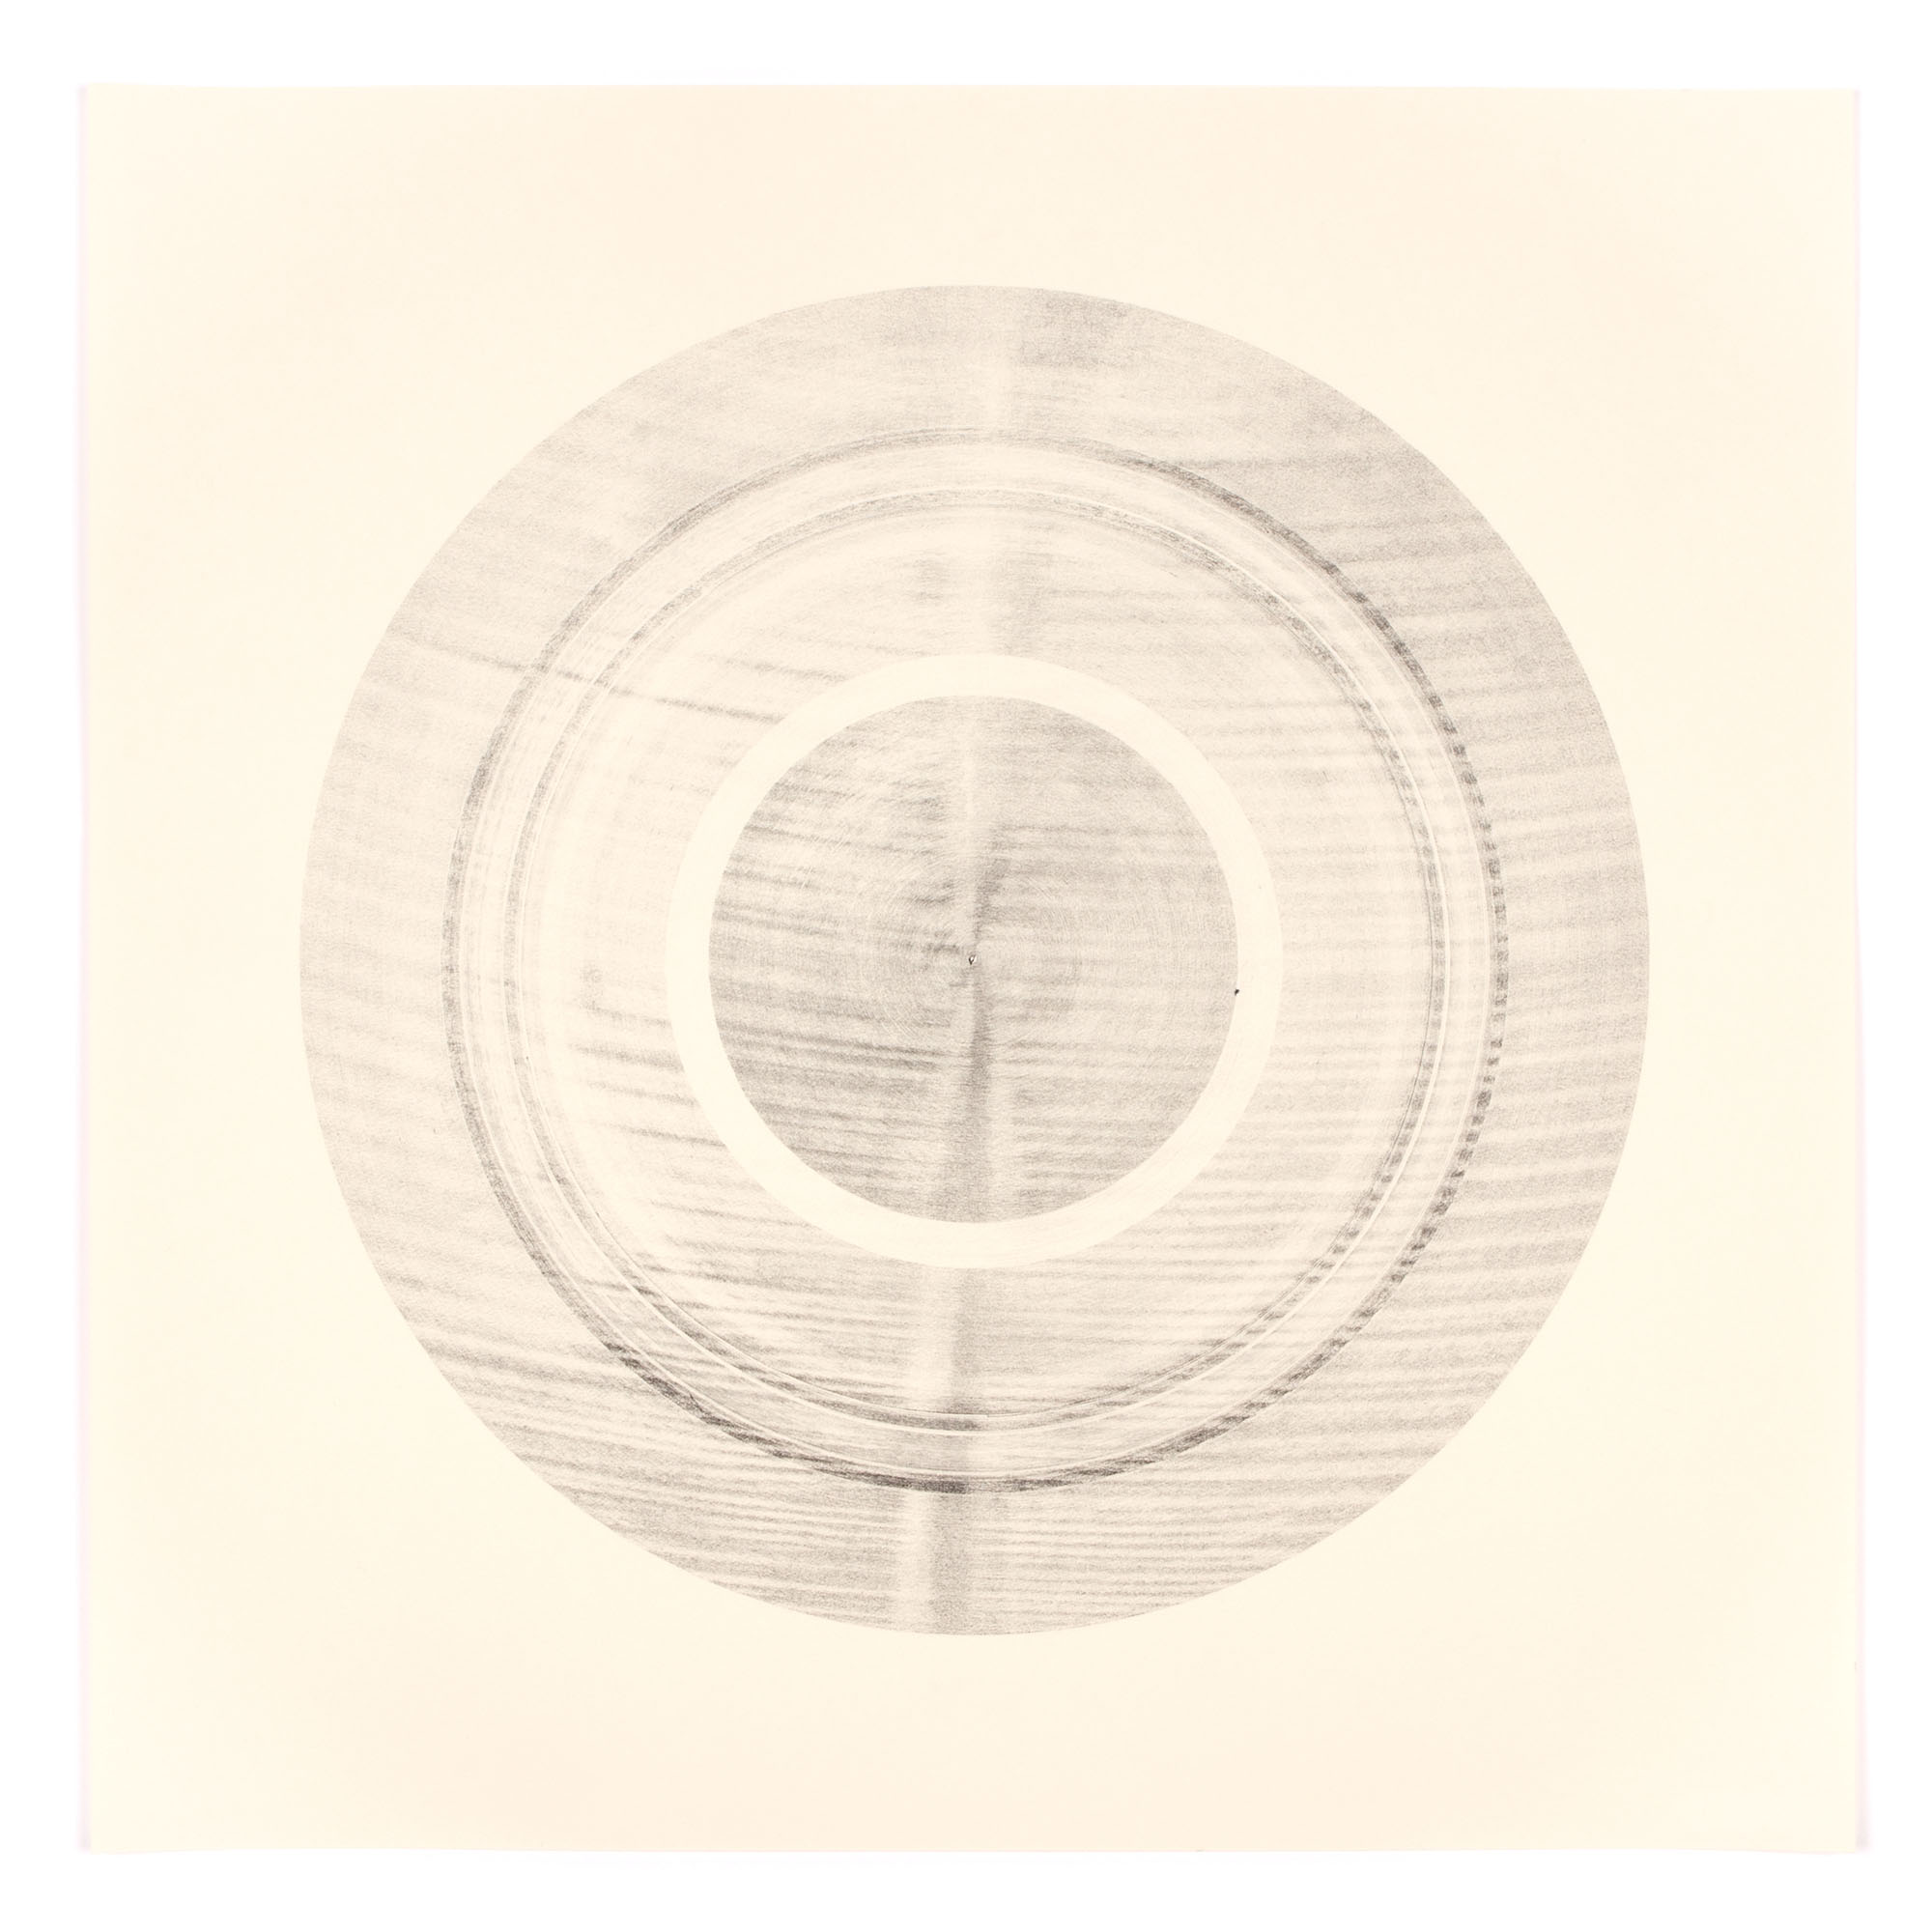
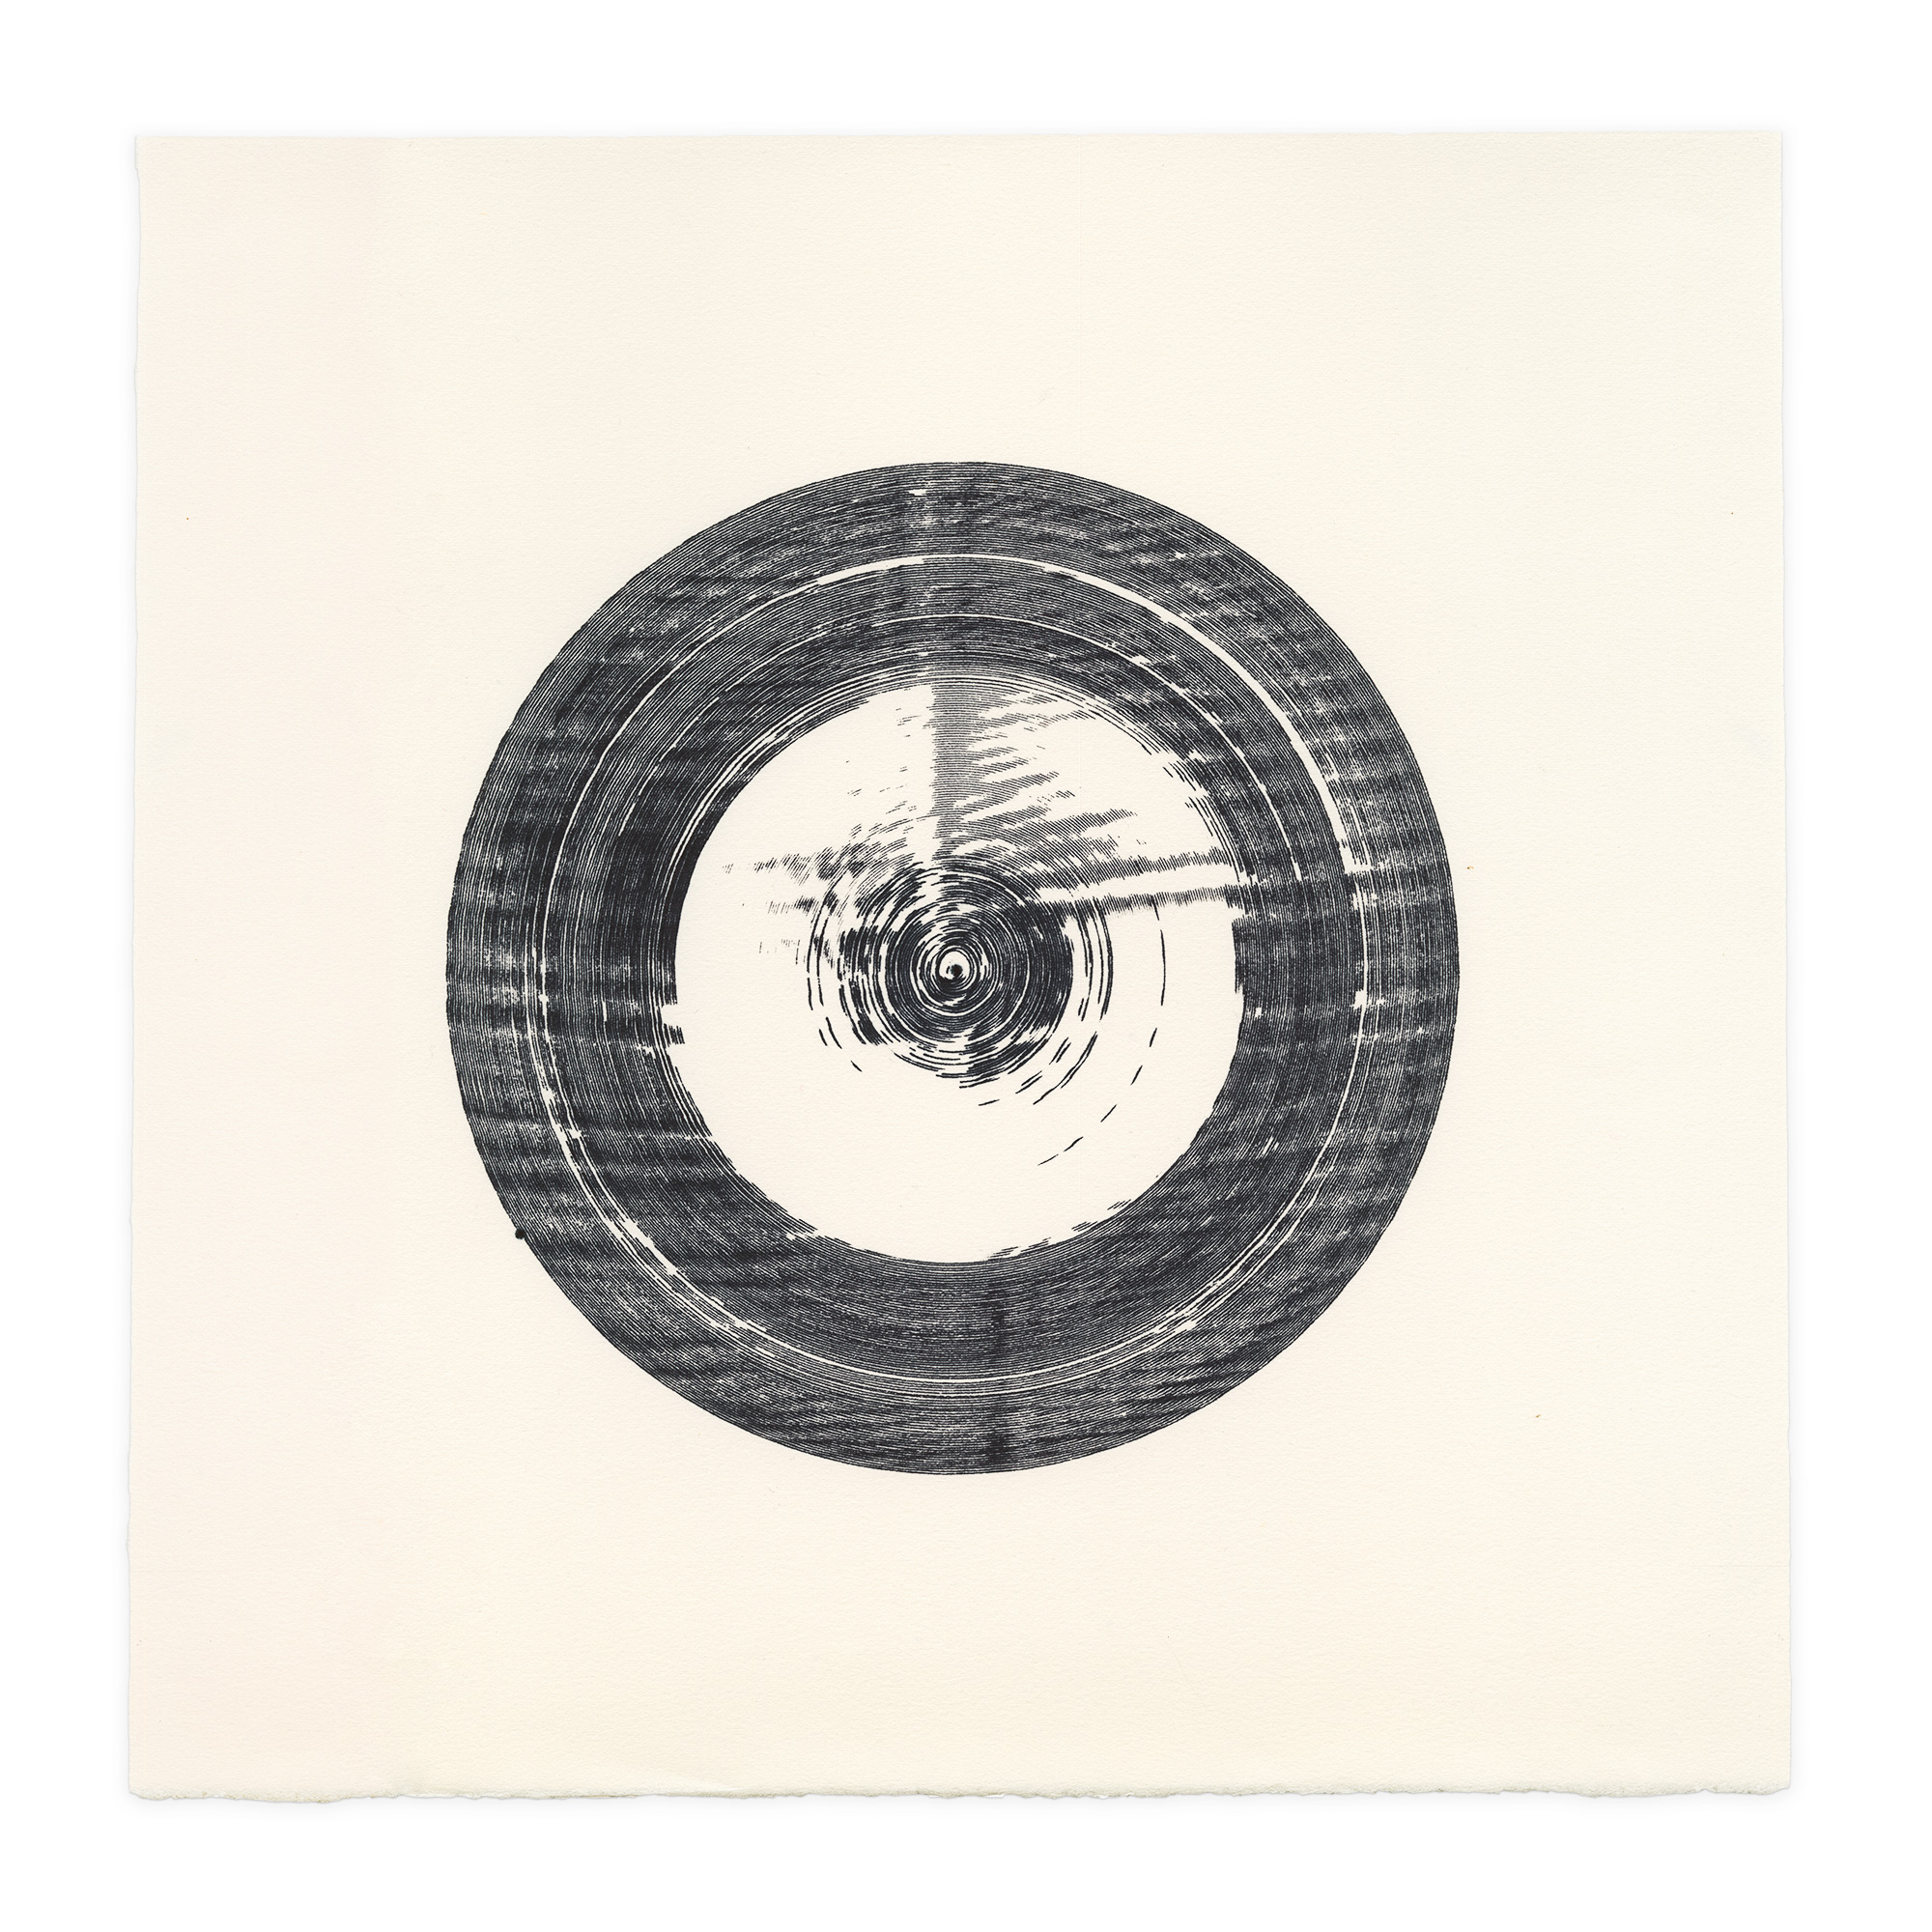
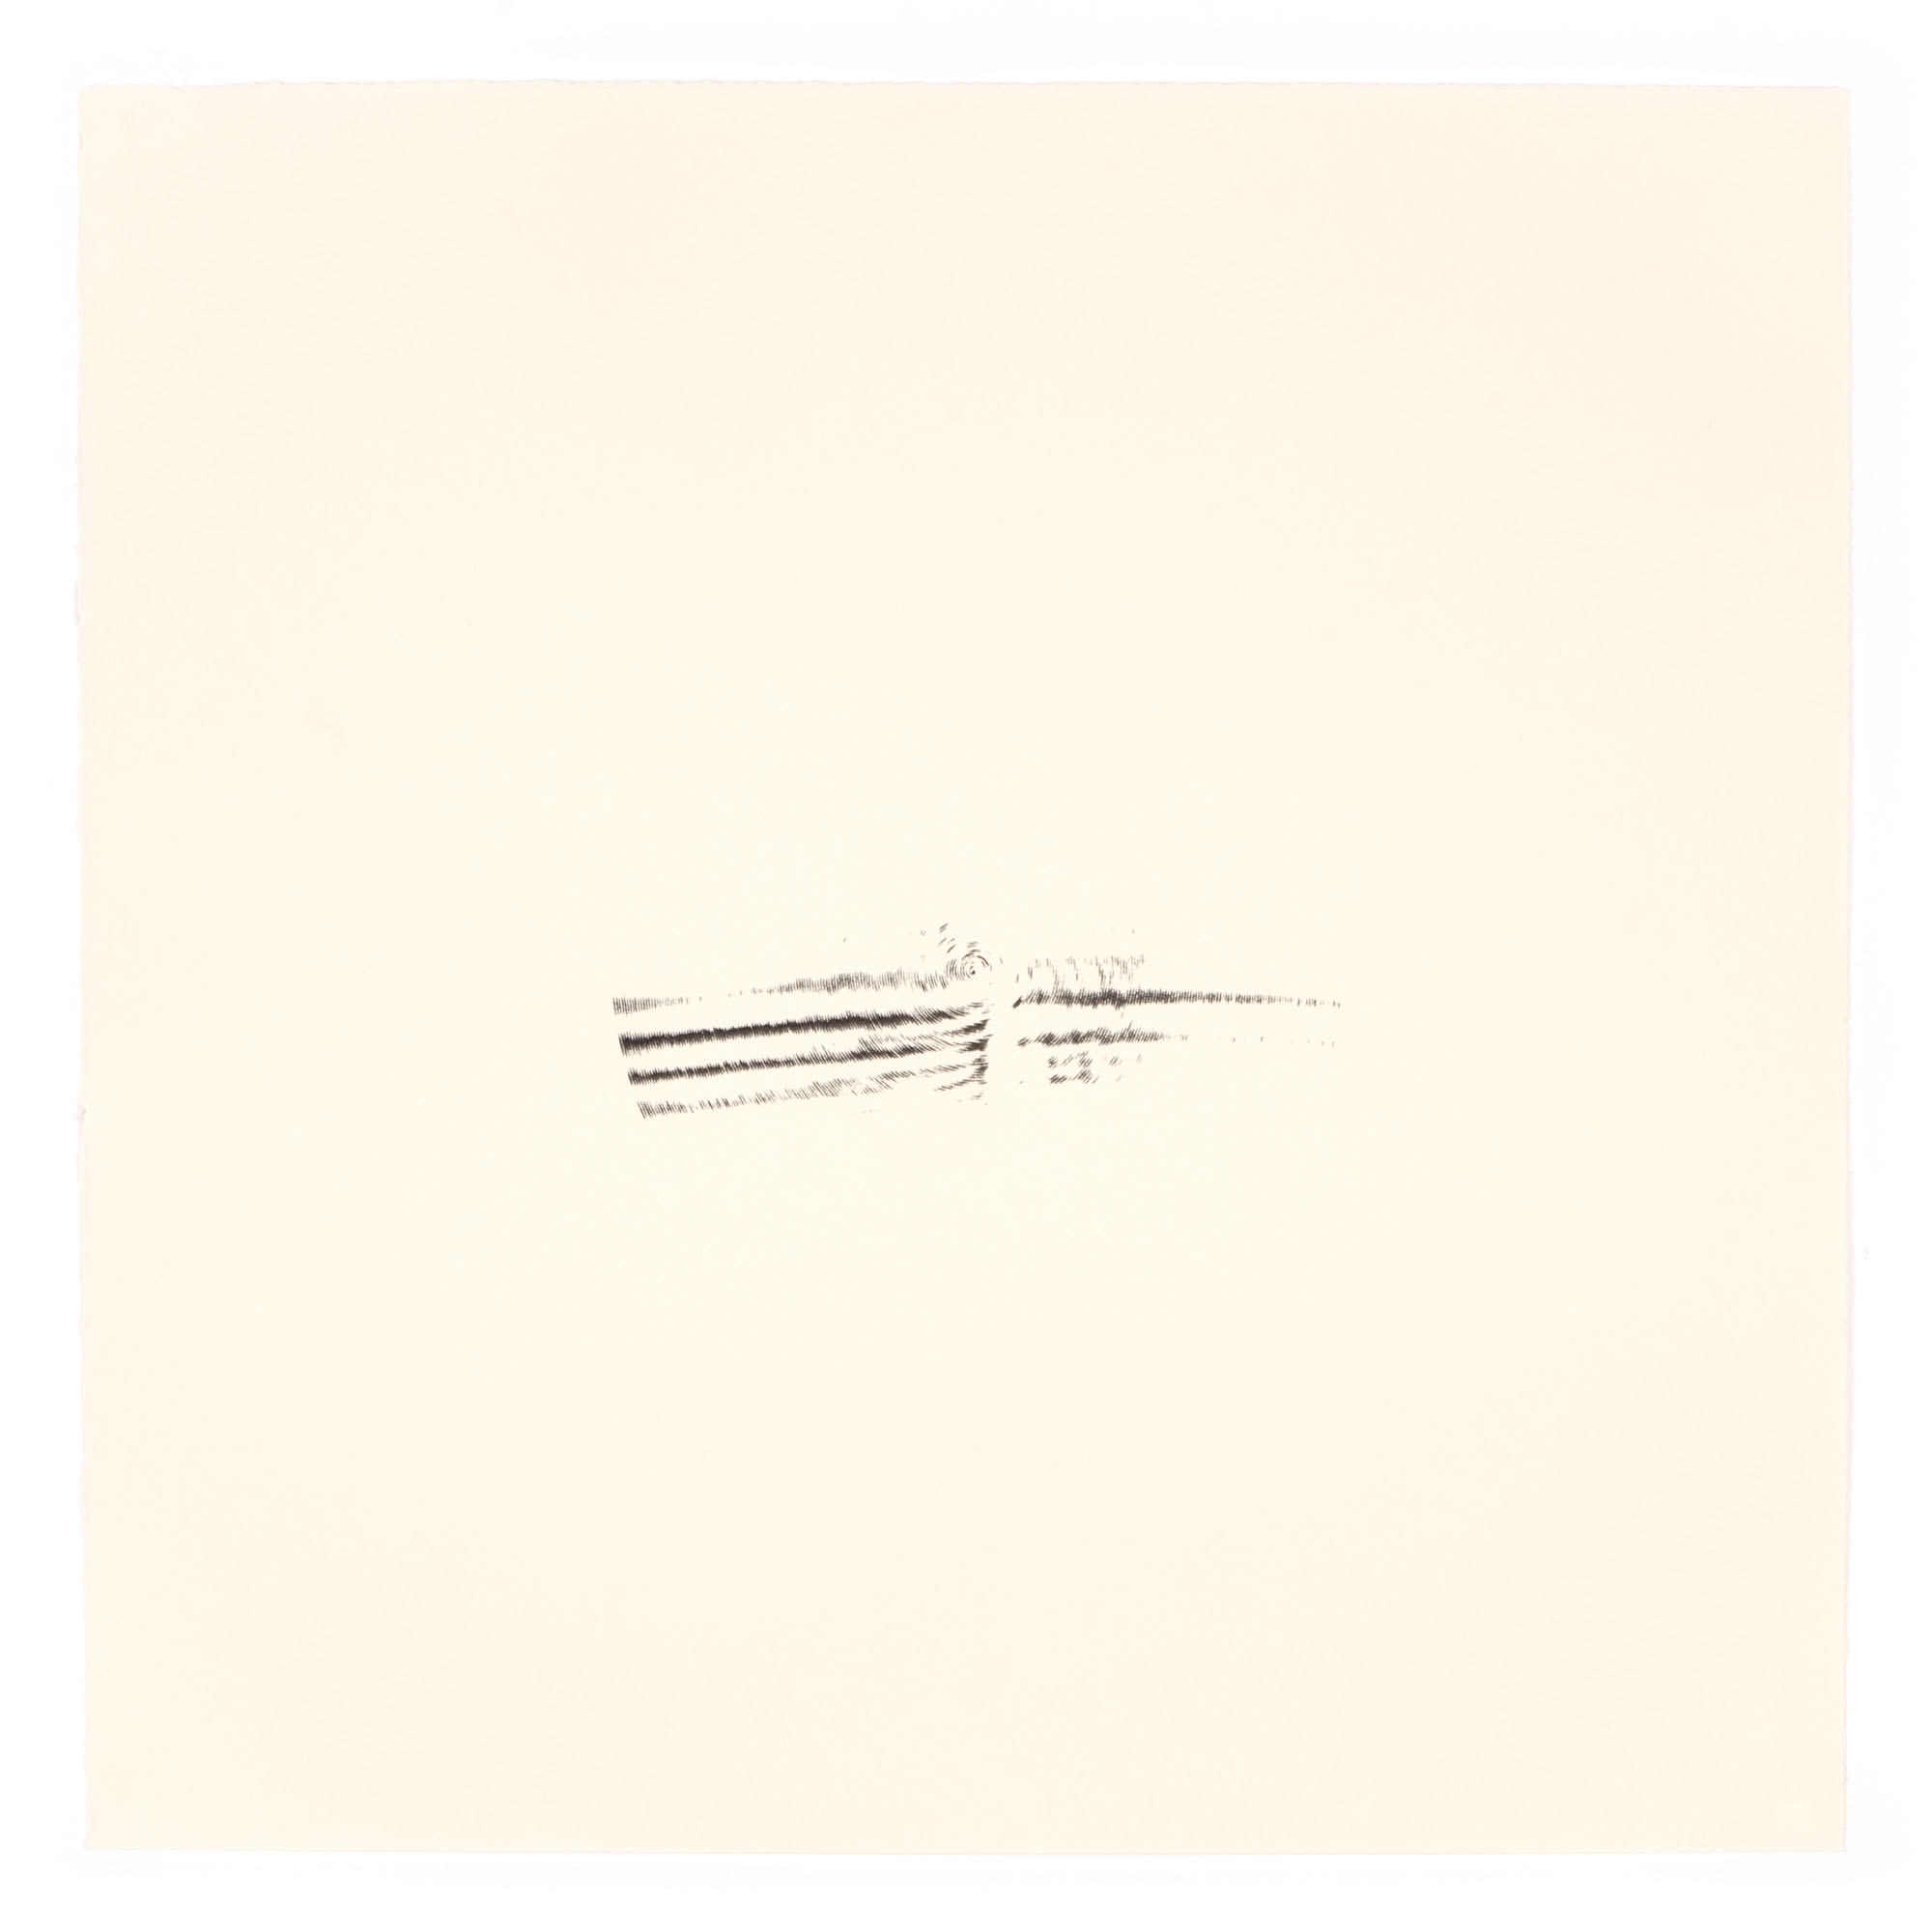
Robotic arms like the UR5 now give us the capability of manipulating matter to the thousandth of an inch and repeating a series of physical actions infinitely many times. This precision and repeatability is common in software, but new to the 'real world.' I programmed one of these robots to draw spirals. Surprisingly, imperfections abound for such a well-built piece of machinery. The gait of the arm as it moves, the base on which it sits, how it holds and grips the pen—even the humidity of the air and topology of the paper—contribute to chaotic behaviors that reveal subtle patterns of movement in the marks drawn. These singularities are, in a way, the fingerprint of the robot—its characteristic essence of being and moving in response to an imperfect world.
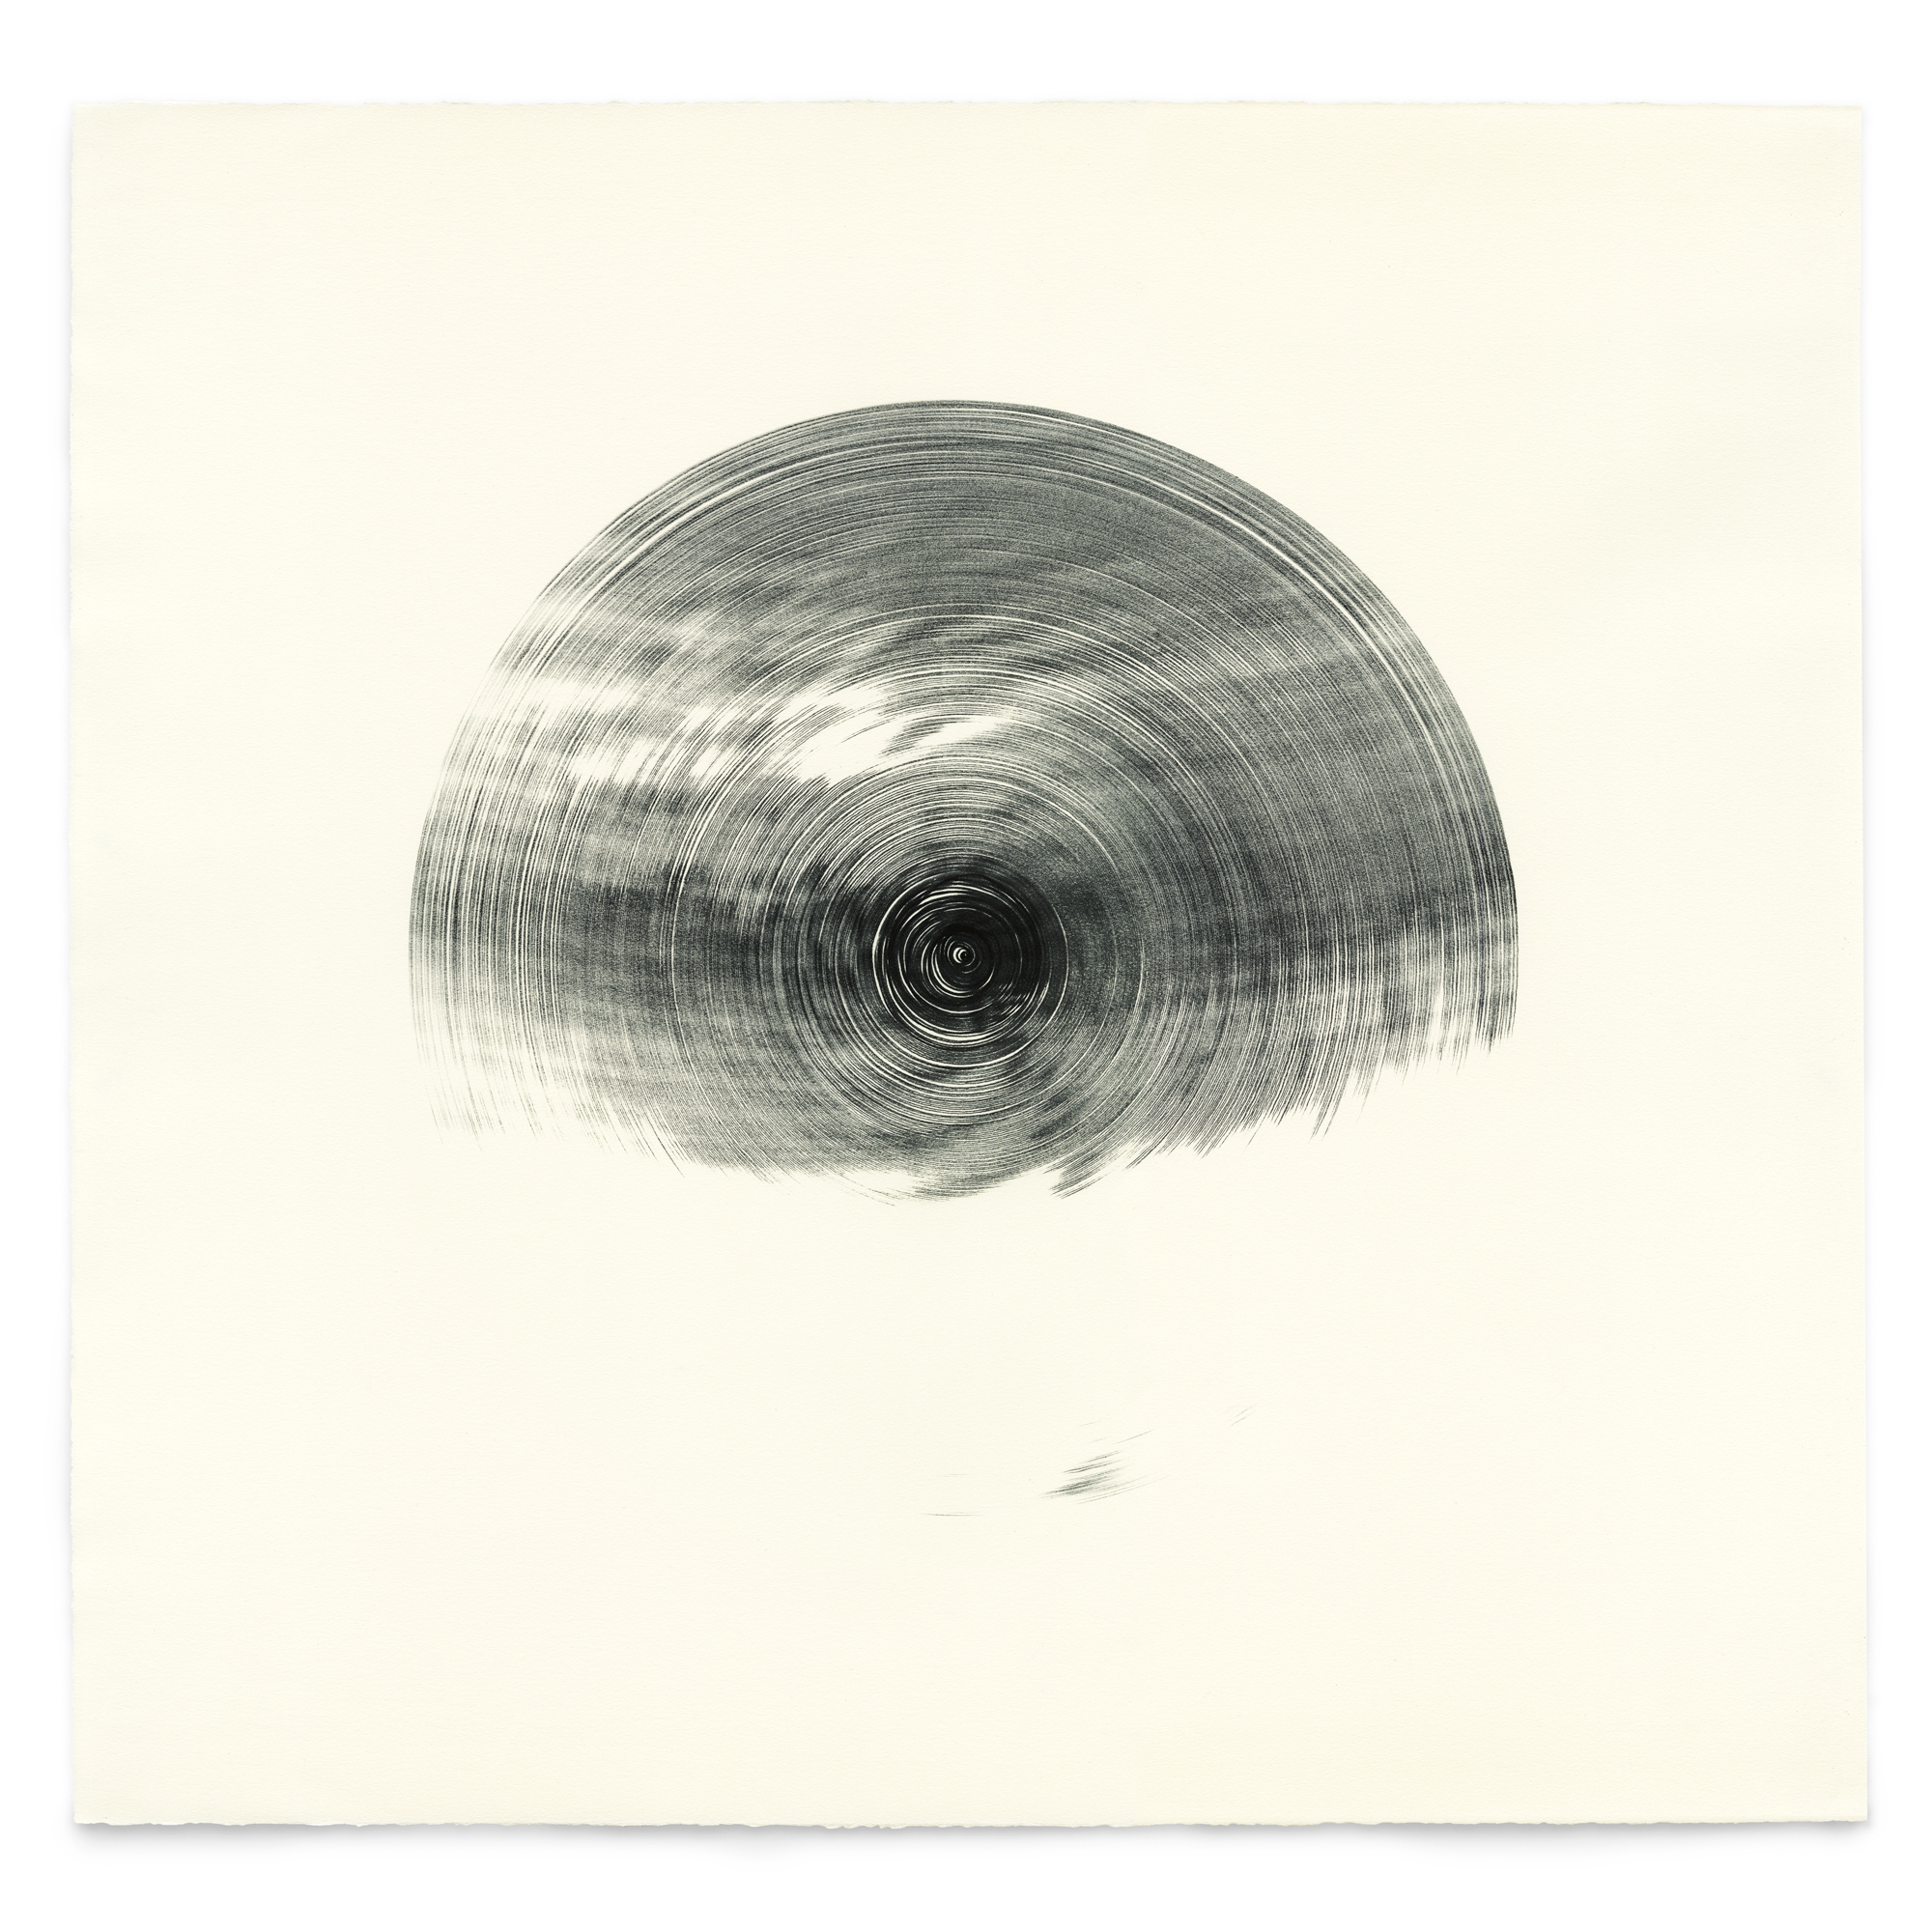
G53, UR5 by Ben Snell: G53 UR5 #001
G53 UR5 #001 19 5/8 x 19 5/8 in (50 x 50 cm)
G53, UR5 by Ben Snell: G53 UR5 #002
G53 UR5 #002 19 5/8 x 19 5/8 in (50 x 50 cm)
G53, UR5 by Ben Snell: G53 UR5 #003
G53 UR5 #003 11 3/4 x 11 3/4 in (30 x 30 cm)
G53, UR5 by Ben Snell: G53 UR5 #004
G53 UR5 #004 9 7/8 x 9 7/8 in (25 x 25 cm)
G53, UR5 by Ben Snell: G53 UR5 #005
G53 UR5 #005 19 5/8 x 19 5/8 in (50 x 50 cm)
G53, UR5 by Ben Snell: G53 UR5 #006
G53 UR5 #006 19 5/8 x 19 5/8 in (50 x 50 cm)
G53, UR5 by Ben Snell: G53 UR5 #007
G53 UR5 #007 19 5/8 x 19 5/8 in (50 x 50 cm)
G53, UR5 by Ben Snell: G53 UR5 #008
G53 UR5 #008 19 5/8 x 19 5/8 in (50 x 50 cm)
G53, UR5 by Ben Snell: G53 UR5 #009
G53 UR5 #009 16 x 16 in (40.5 x 40.5 cm)
G53, UR5 by Ben Snell: G53 UR5 #010
G53 UR5 #010 11 3/4 x 11 3/4 in (30 x 30 cm)
G53, UR5 by Ben Snell: G53 UR5 #011
G53 UR5 #011 12 3/4 x 12 3/4 in (32.5 x 32.5 cm)